カテゴリ
01 Robotic Manipulation: Imitation Learning 02 Mixed Reality-based Robot Interface 03 Legged Robot Learning 04 Underwater Robots 05 Autonomous Mobile Robot 06 Robotics Learning Materials 07 Intelligent Robot System Imitation Learning for Robot Arm (Position / Force Control) 2026
/
Preprint
Video Friday Paper
· Project
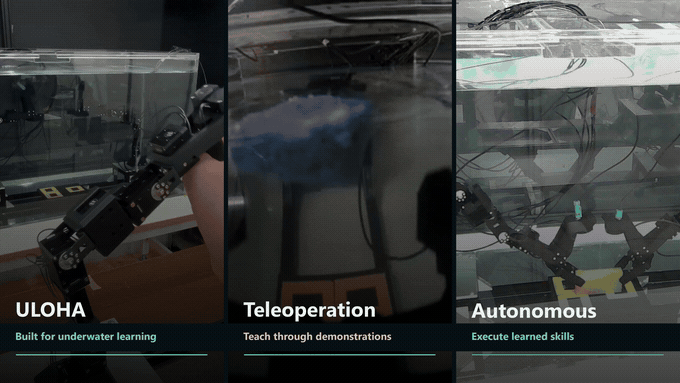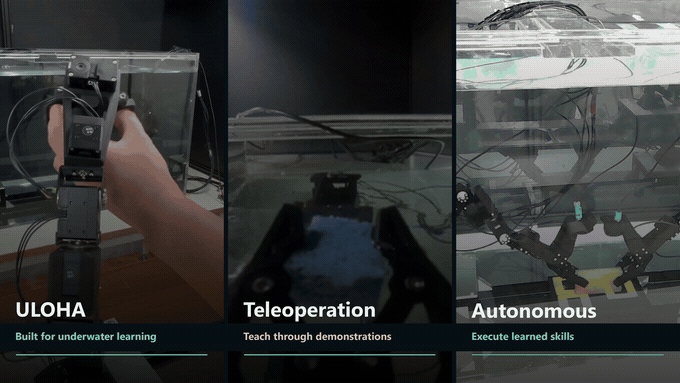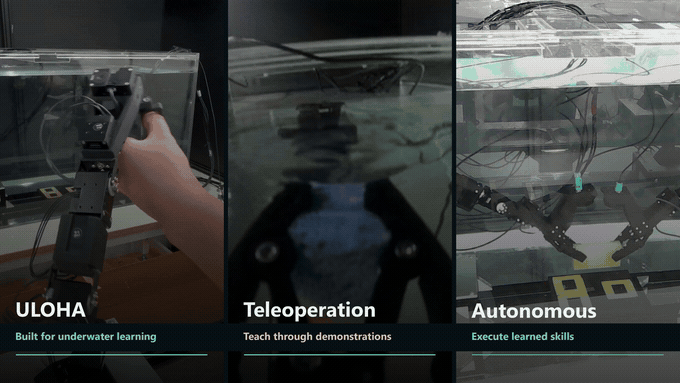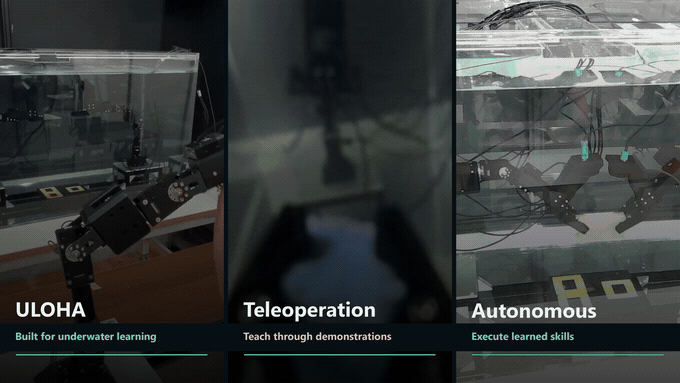
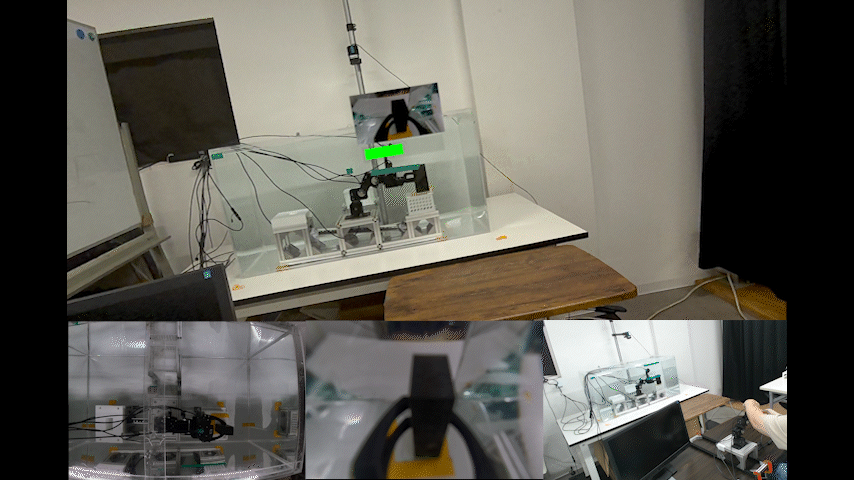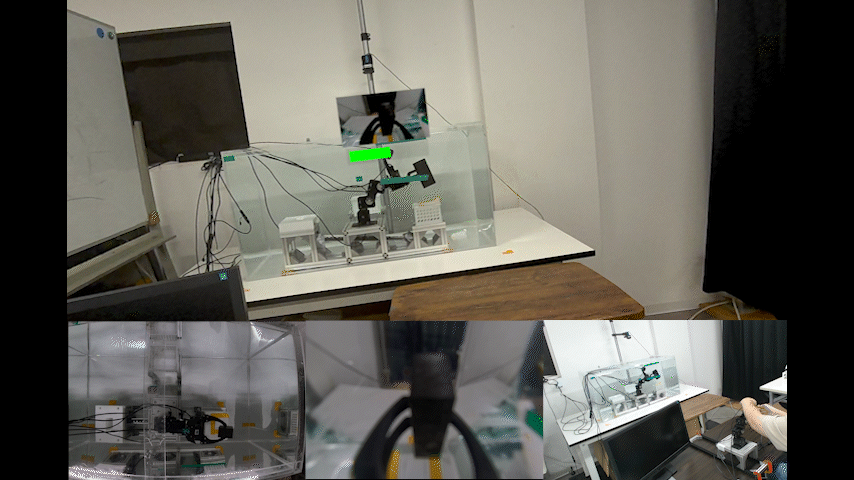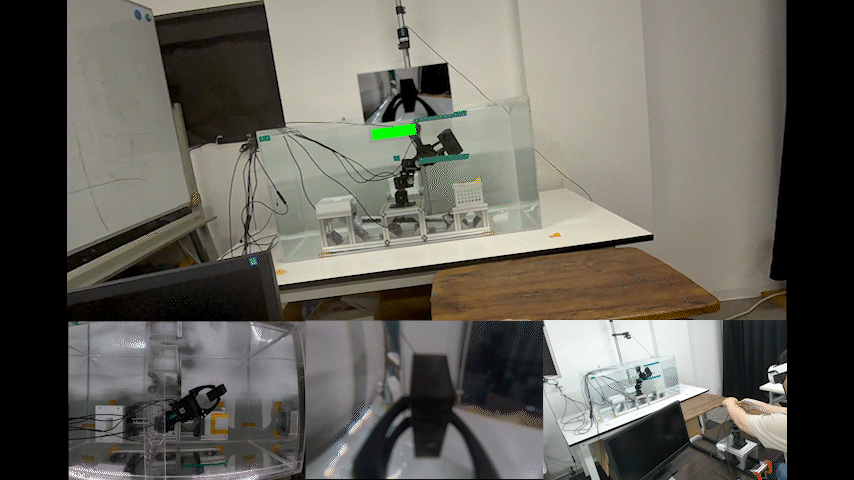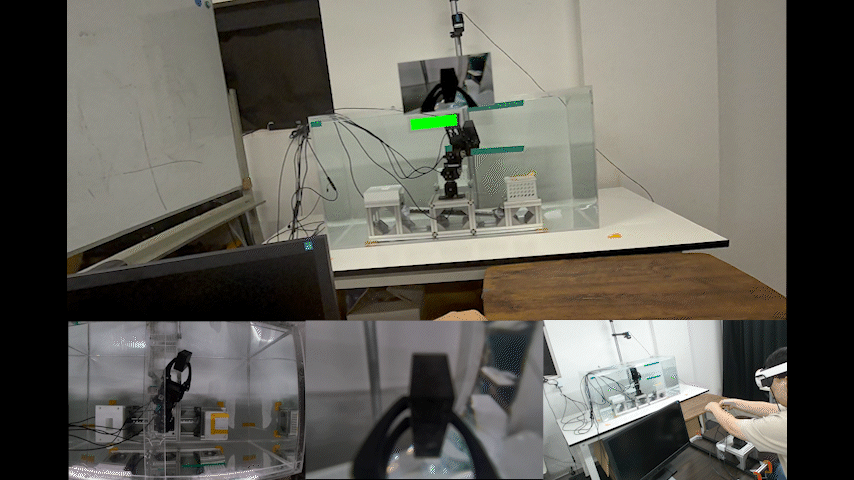
ULOHA: An Underwater Bimanual Robot System for Robot Learning
独自のリーダー・フォロワー機構と、LeRobotを水中双腕ロボット向けに拡張したソフトウェアにより、遠隔操作・実演データ収集・自律実行を統合したロボット学習プラットフォーム。9種類の水中タスクでACTを評価し、選択したタスクではDiffusion PolicyとSmolVLAの水中実機への適用も検証。浮力を利用した操作、気泡の影響、動作実行のタイミング、SmolVLAのReal-Time Chunking(RTC)、空中・水中間の転移も評価。ハードウェア設計とソフトウェアはオープンソースとして公開予定。
2026
/
Preprint Paper
· Project
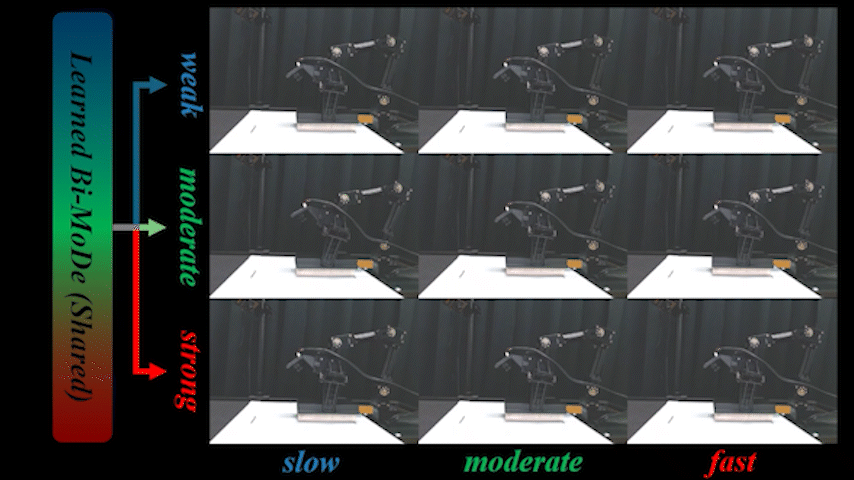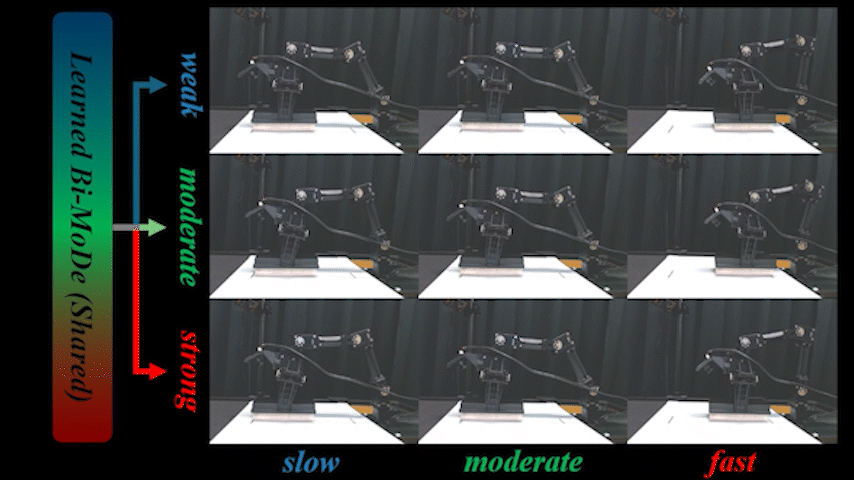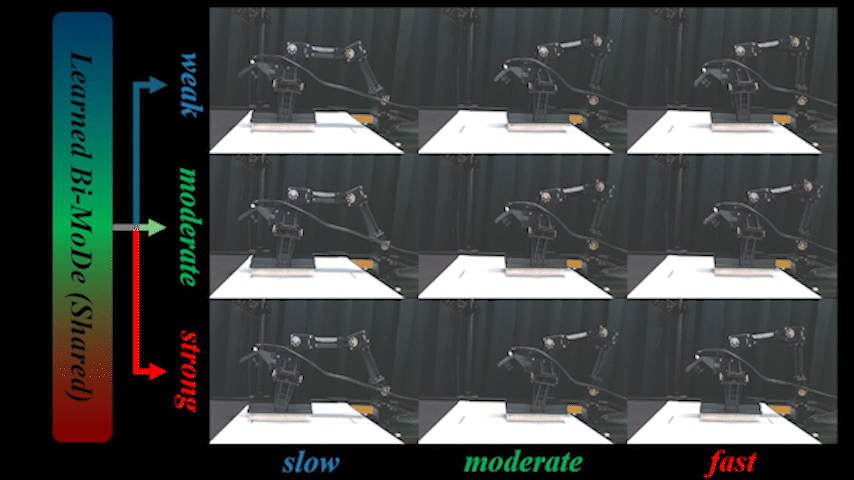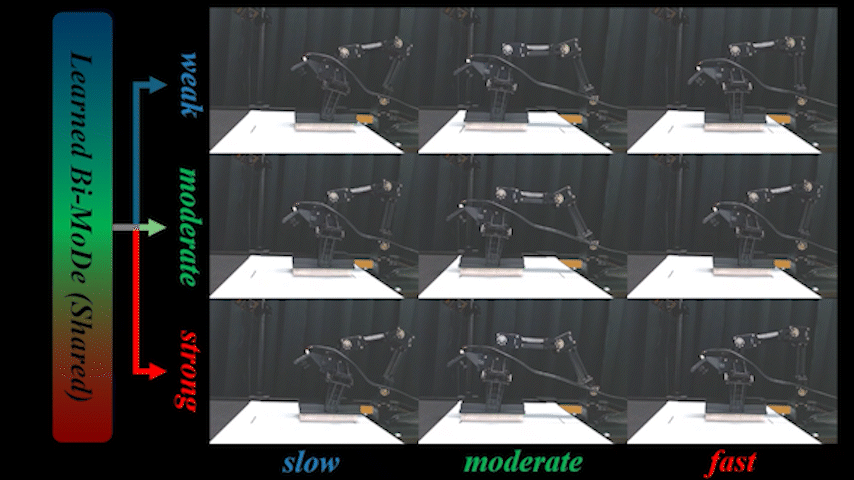
Bi-MoDe: Bilateral Control-based Imitation Learning via Modifier-Conditioned Decoding for Modulation of Execution Speed and Contact Intensity
バイラテラル制御に基づく模倣学習において、動作の「速さ」と「接触の強さ」を推論時に指定できるフレームワーク.修飾指示に対応する潜在変数をadaLN-Zeroでアクションデコーダの全層に注入し、実機のホワイトボード拭き取りタスクで力指示への追従性を大幅に改善.
2026
/
IEEE IROS
Video Friday Paper
· Project
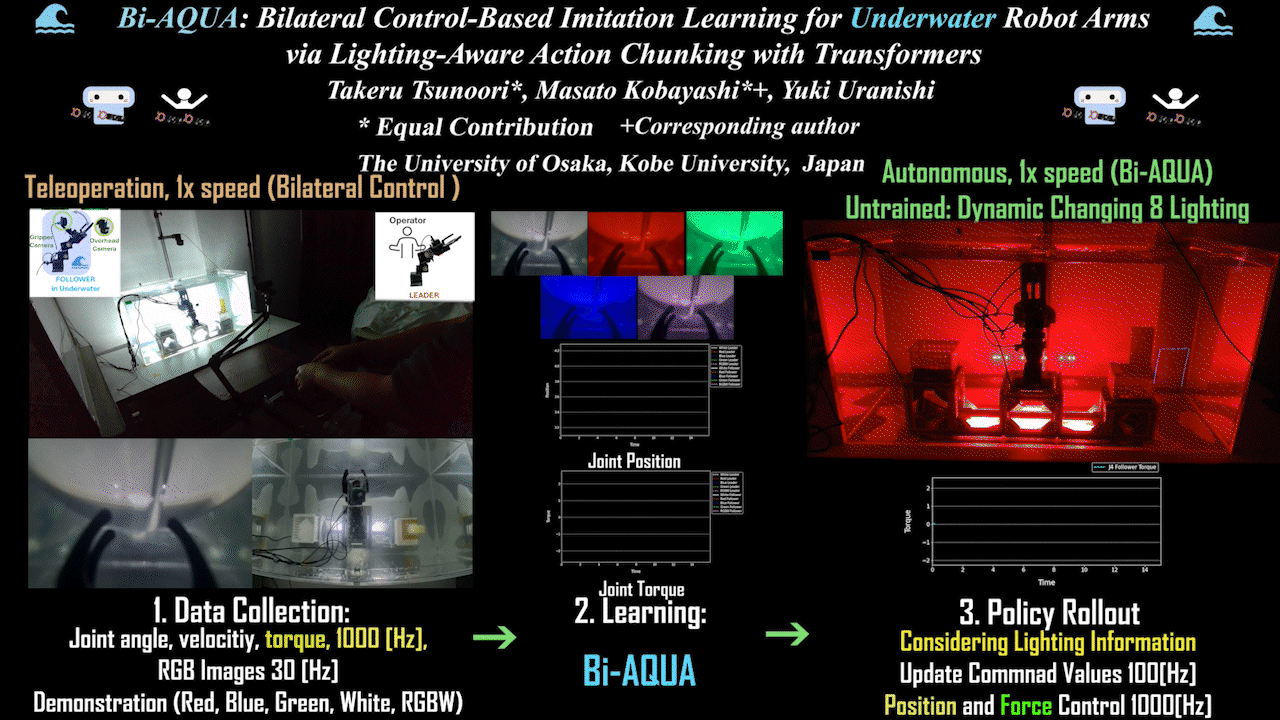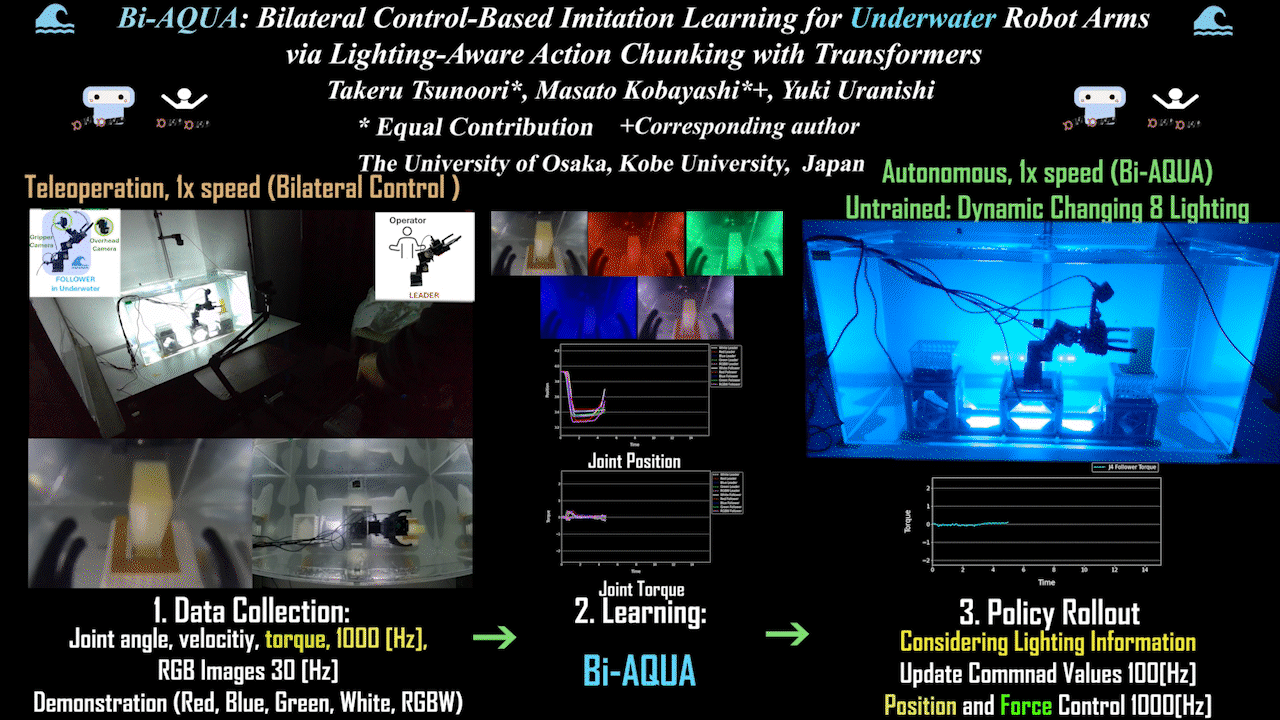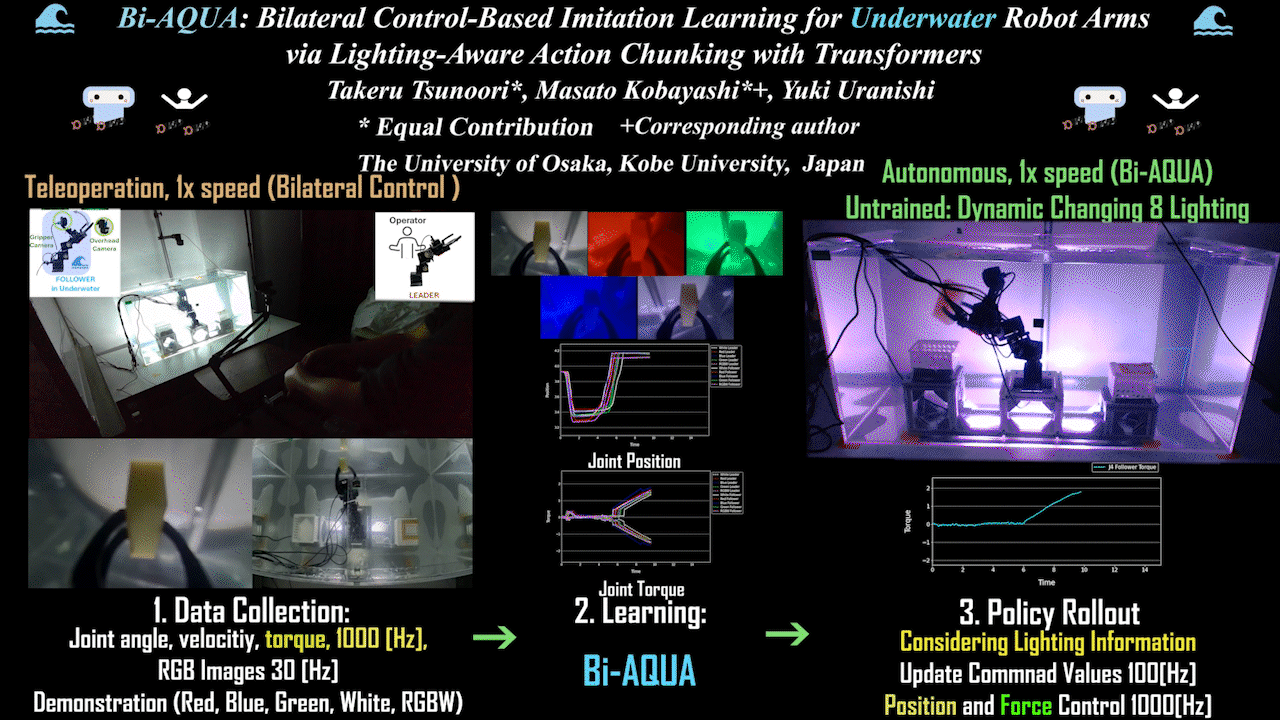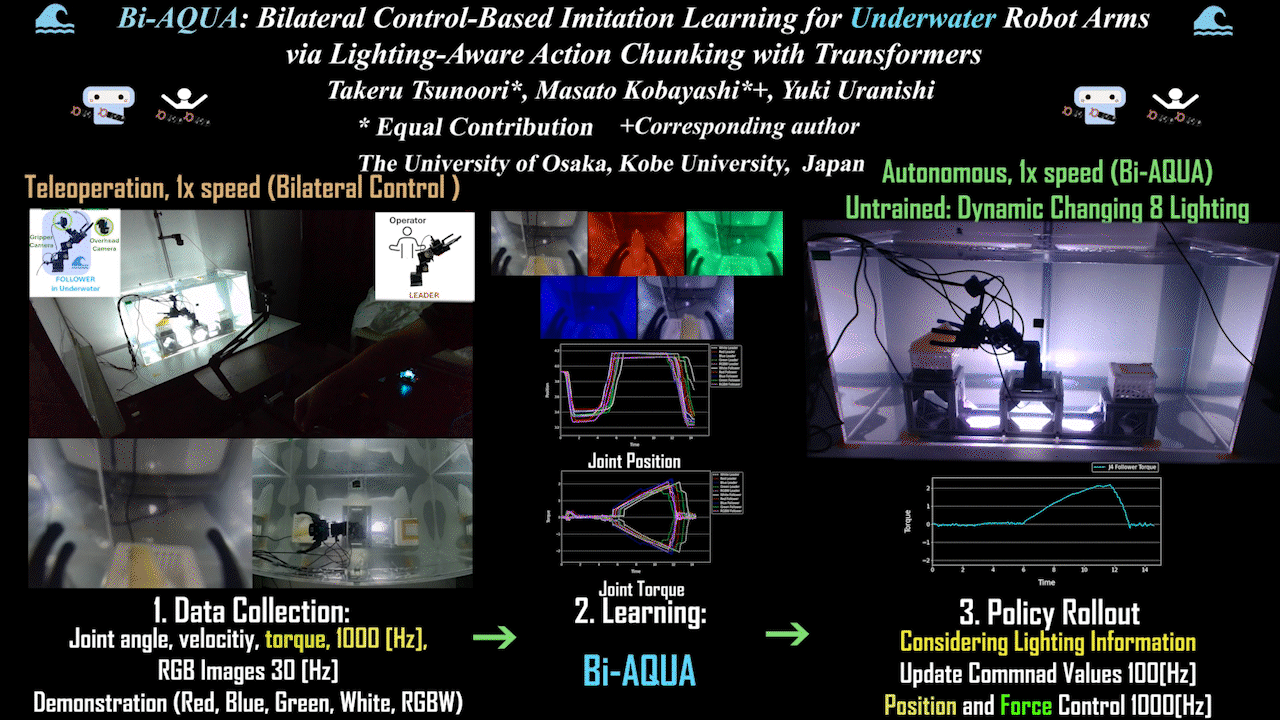
Bi-AQUA: Bilateral Control-Based Imitation Learning for Underwater Robot Arms via Lighting-Aware Action Chunking with Transformers
世界初の水中バイラテラル制御に基づく模倣学習を実世界で実現.水中・水上の画像・照明・位置・力情報に基づくロボット学習モデルと位置・力制御による自律動作
2026
/
IEEE IROS Paper
· Project
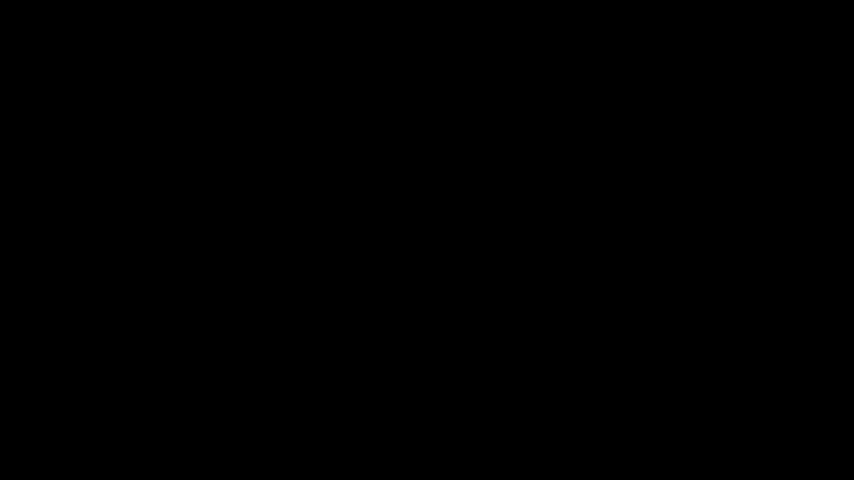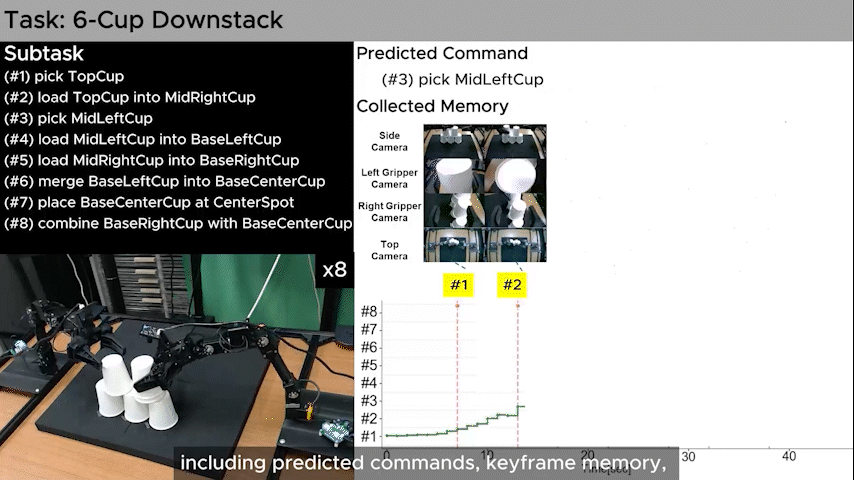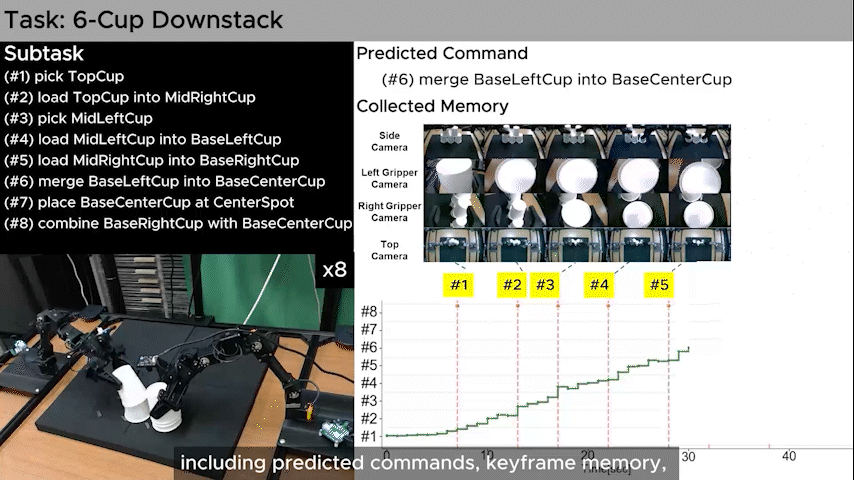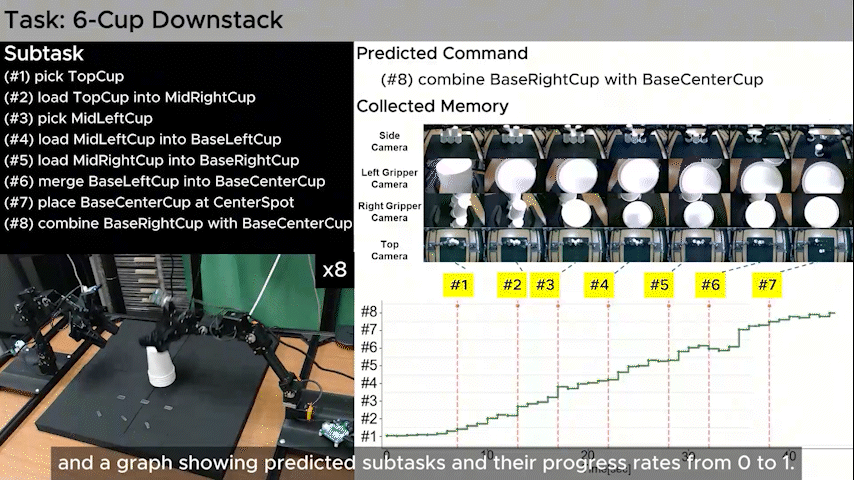
Bilateral Control-Based Multimodal Hierarchical Imitation Learning via Subtask-Level Progress Rate and Keyframe Memory for Long-Horizon Contact-Rich Robotic Manipulation
長期のコンタクトリッチなマニピュレーションのためのバイラテラル制御に基づくのマルチモーダル階層型模倣学習フレームワーク.キーフレームメモリとサブタスクレベルの進捗率を統合して階層的協調を安定化し、単腕・双腕の実機タスクでフラットおよびアブレーション版を上回る一貫した改善を示す.
2026
/
IEEE ARSO Paper
· Project
Bi-VLA: Bilateral Control-Based Imitation Learning via Vision-Language Fusion for Action Generation
言語による視覚情報の調整によるバイラテラル制御に基づく模倣学習.自然言語による指示と視覚情報を統合してアクション生成を実現.
2025
/
IEEE RO-MAN
Video Friday Paper
· Project
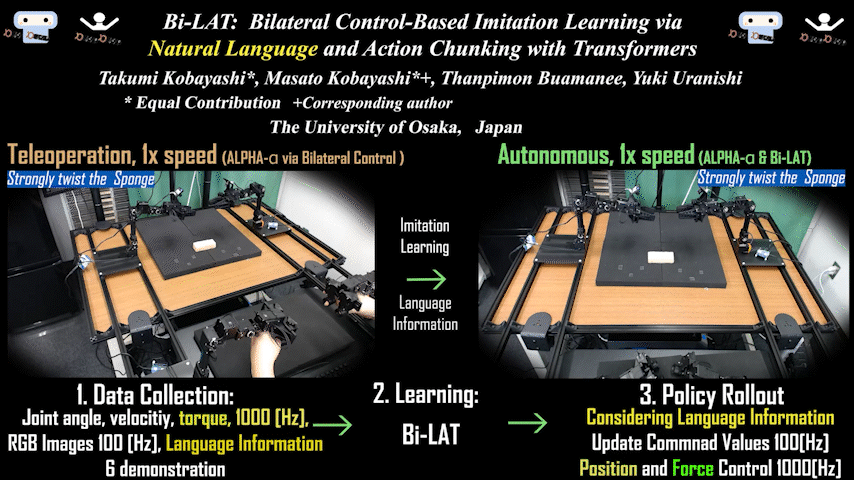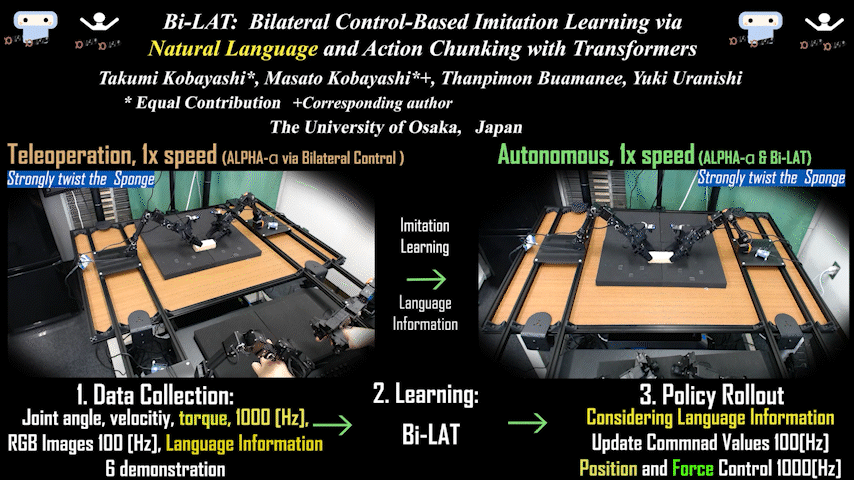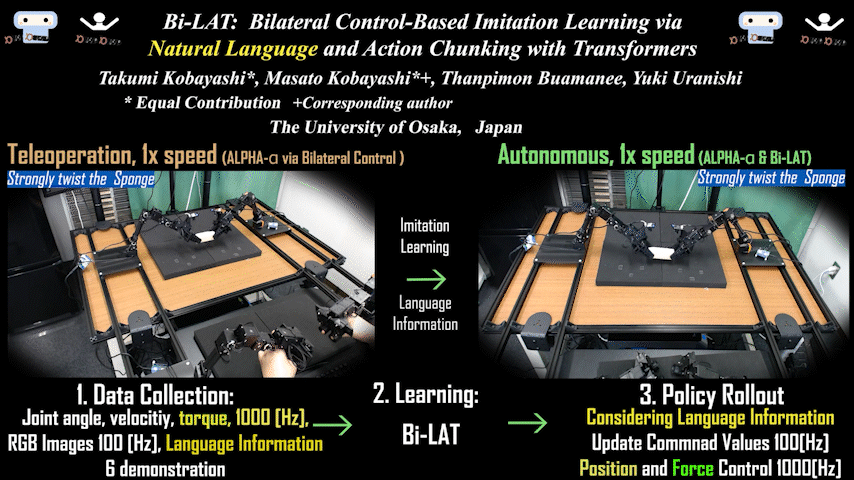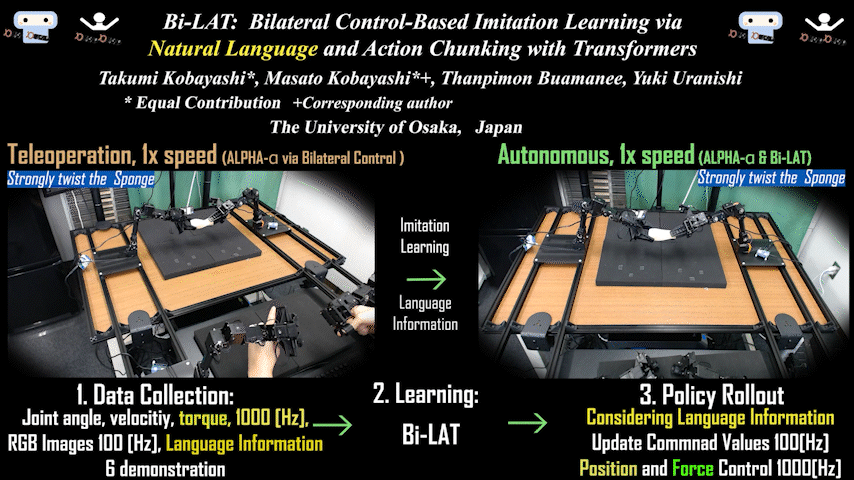
Bi-LAT: Bilateral Control-Based Imitation Learning via Natural Language and Action Chunking with Transformers
自然言語とアクションチャンキングを組み合わせたバイラテラル制御に基づく模倣学習.言語指示により力加減を考慮したロボット操作を実現.
2025
/
IEEE Access
Video Friday Paper
· Project
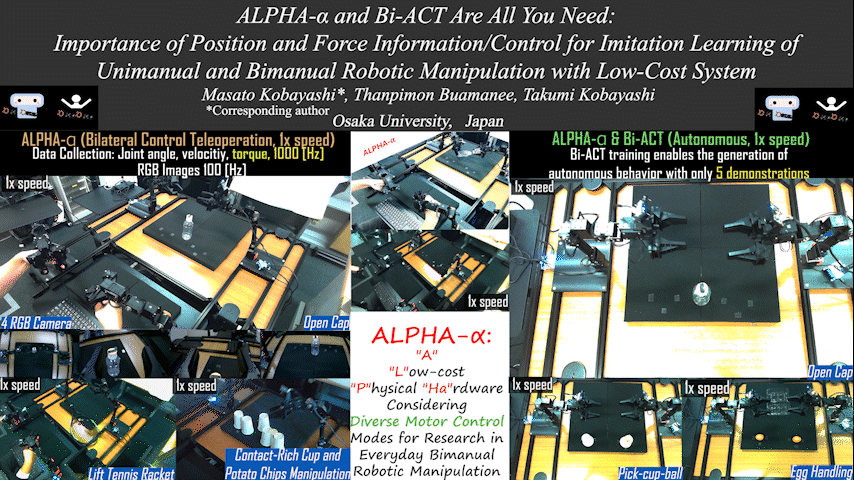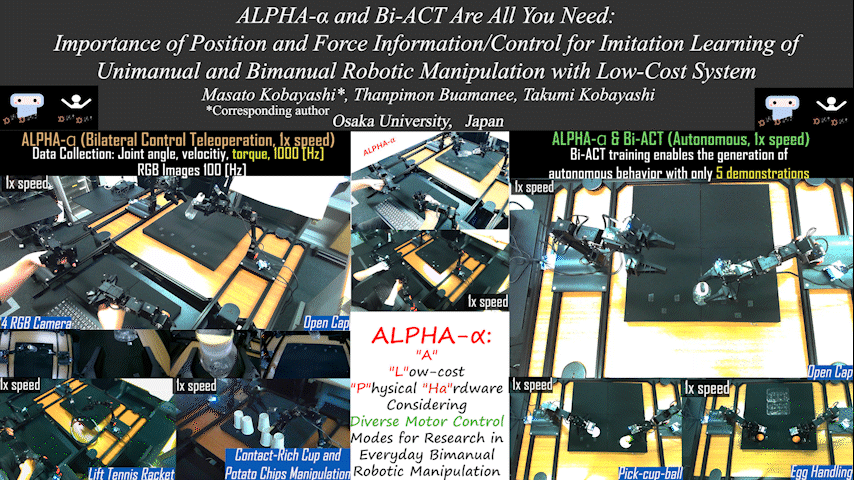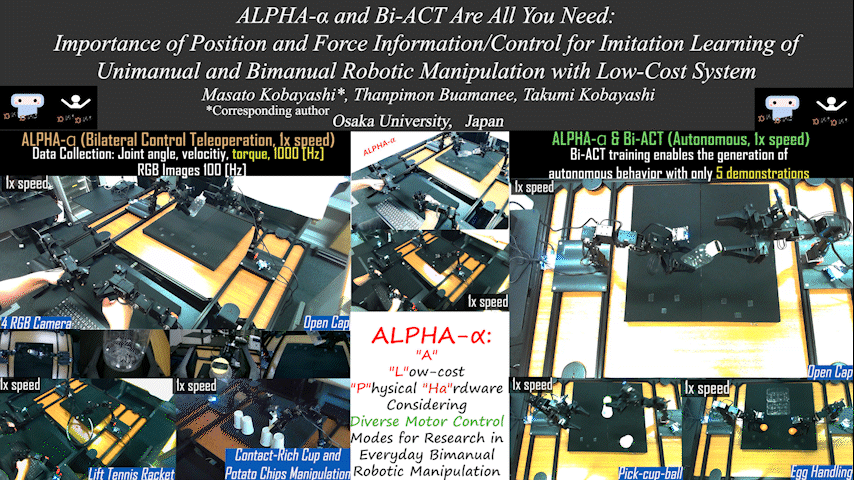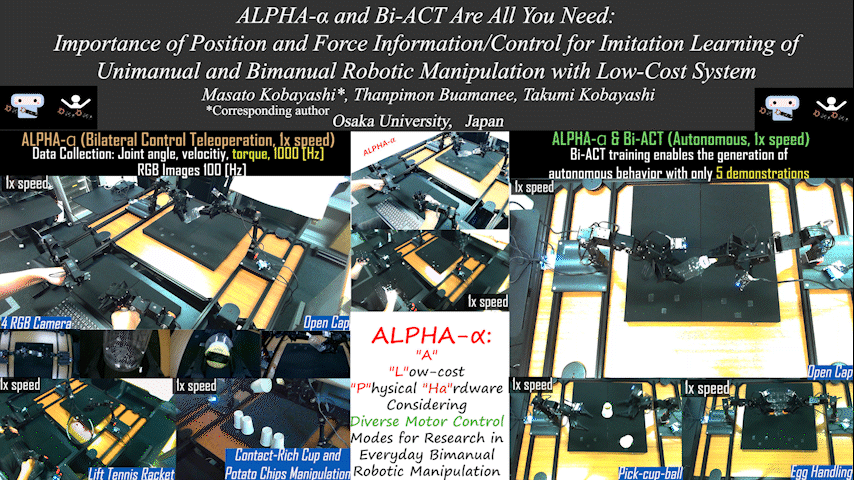
ALPHA-α and Bi-ACT Are All You Need: Importance of Position and Force Control and Information in Imitation Learning for Unimanual and Bimanual Robotic Manipulation
日常タスクにおける研究用として、低コストな単腕および双腕ロボット操作における位置・力制御と情報の重要性を提案.バイラテラル制御に基づく模倣学習Bi-ACTの効果を実証.卵運搬やペットボトルのキャップあけなど.
2025
/
IEEE ICRA Paper
· Project
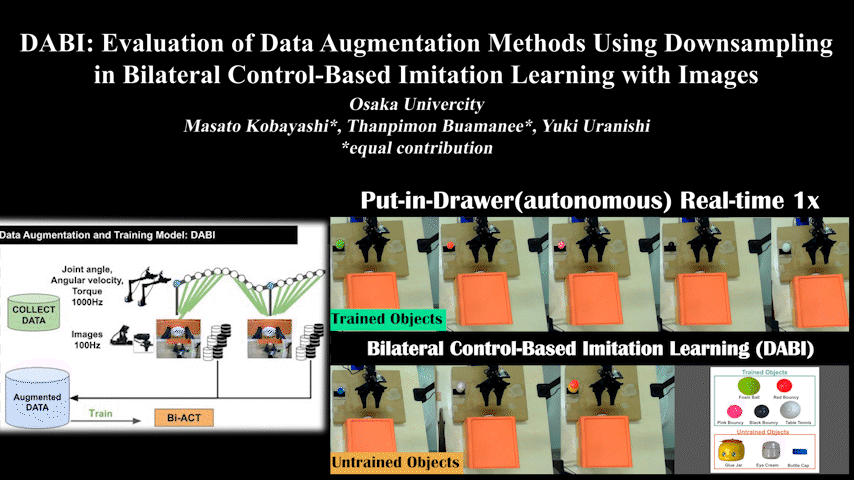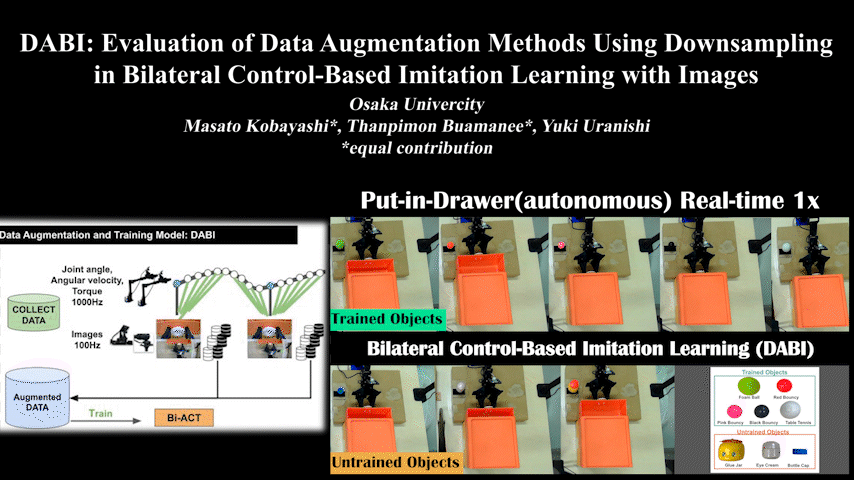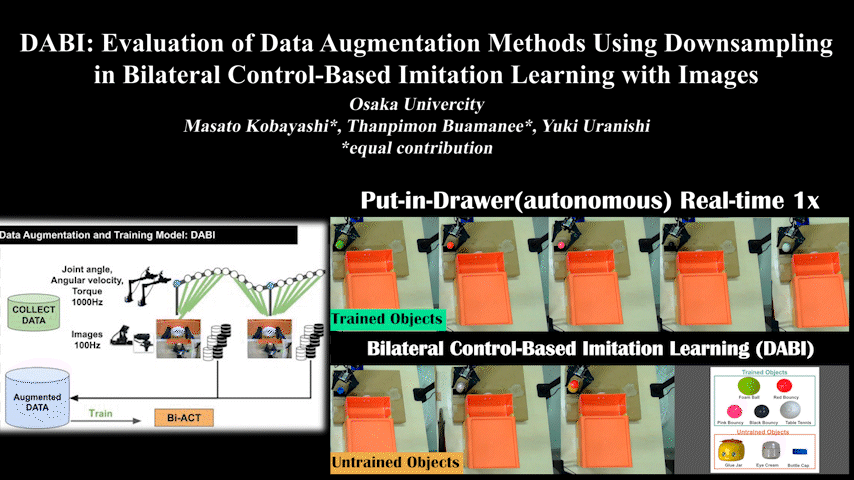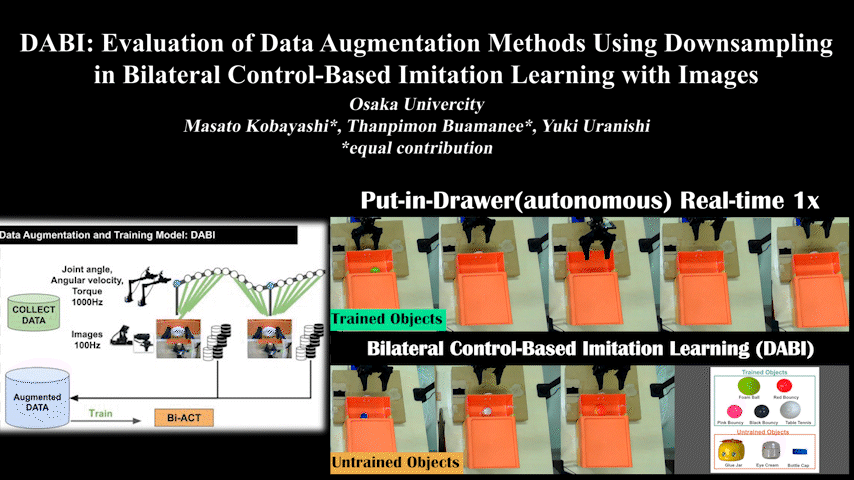
DABI: Evaluation of Data Augmentation Methods Using Downsampling in Bilateral Control-Based Imitation Learning with Images
画像を用いたバイラテラル制御に基づく模倣学習における、ダウンサンプリングを用いたデータ拡張手法の評価.異なるセンサ周波数への対応.
2024
/
IEEE AIM Paper
· Project
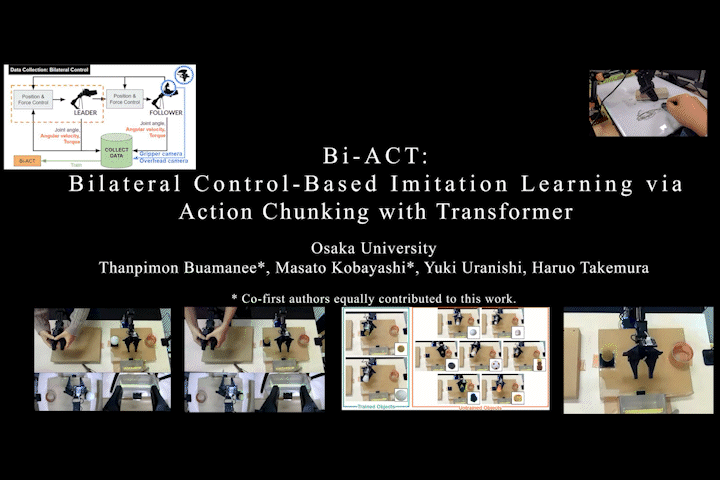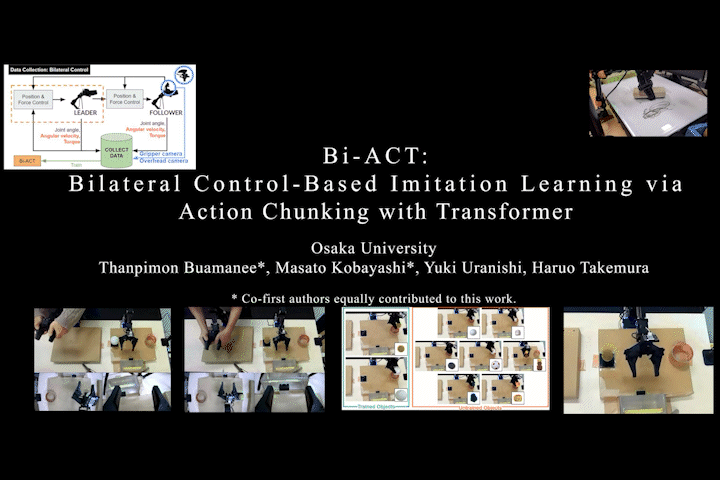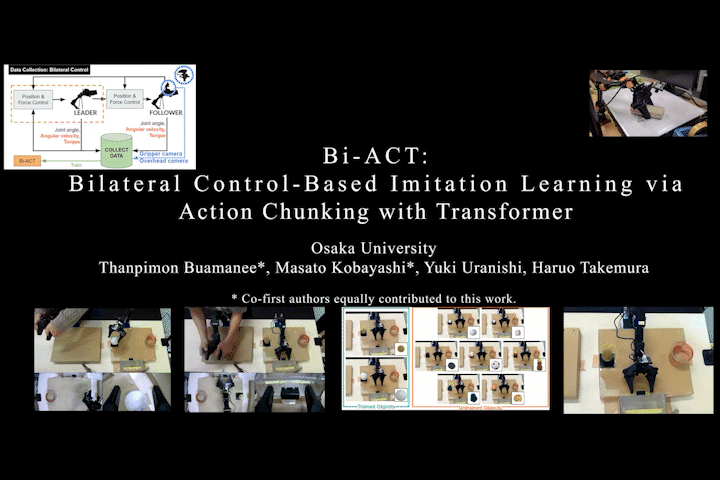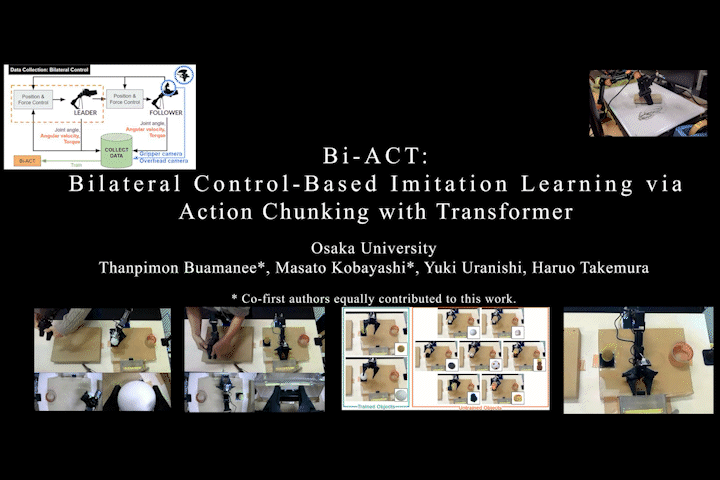
Bi-ACT: Bilateral Control-Based Imitation Learning via Action Chunking with Transformer
ALOHA/ACTで有名なAction Chunking with Transformers (ACT)と位置と力制御のバイラテラル制御に基づく模倣学習を融合させたBi-ACTの提案.
未学習の物体の汎化等には、力制御の重要性が明らかになった.
2024
/
IEEJ Journal Paper
· Project
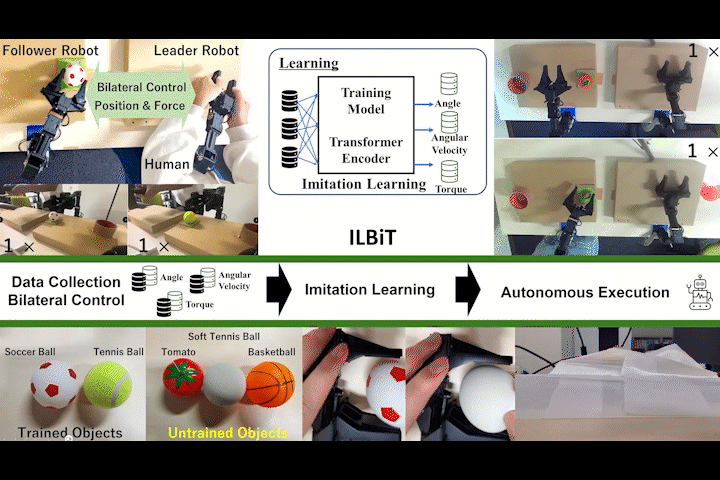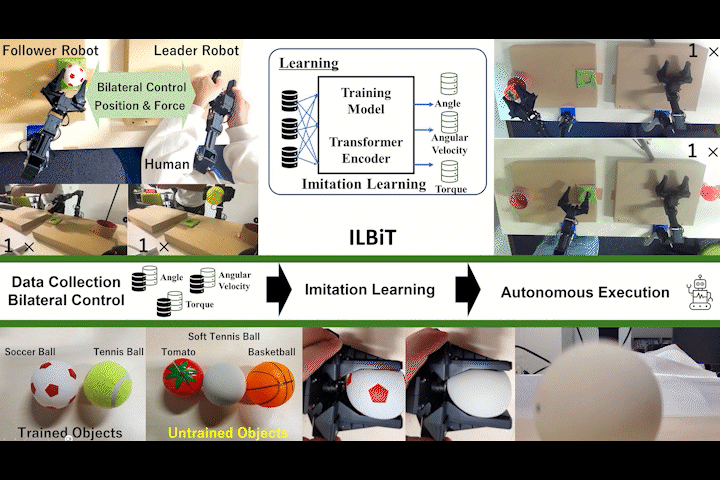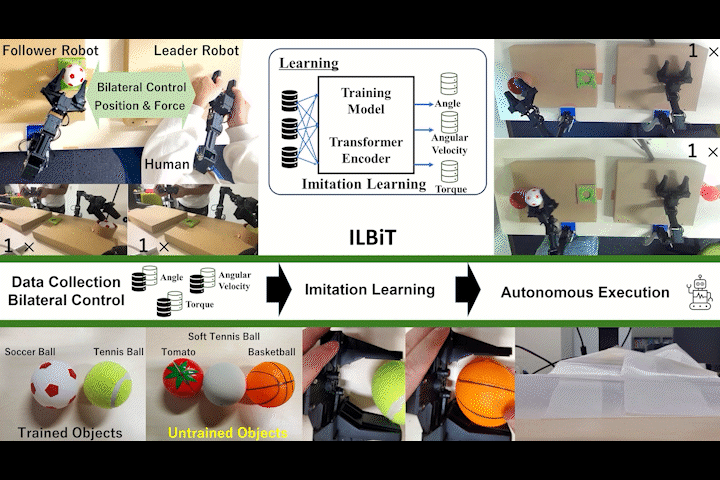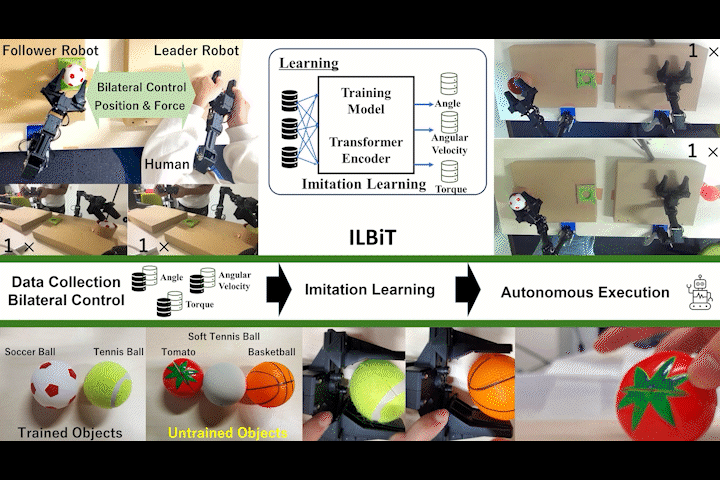
ILBiT: Imitation Learning for Robot Using Position and Torque Information based on Bilateral Control with Transformer
Transformer Encoderを活用した位置とトルク情報を用いたバイラテラル制御に基づく模倣学習.
2023
/
IEEE Humanoids Paper
· Project
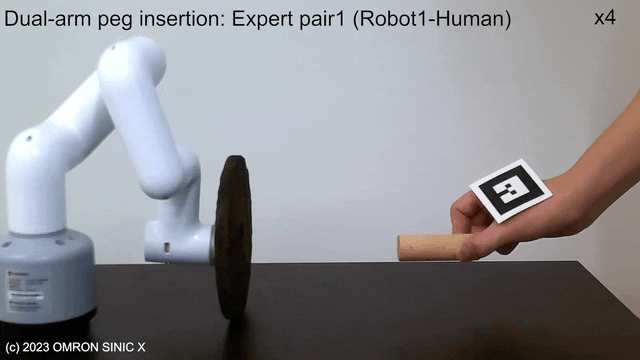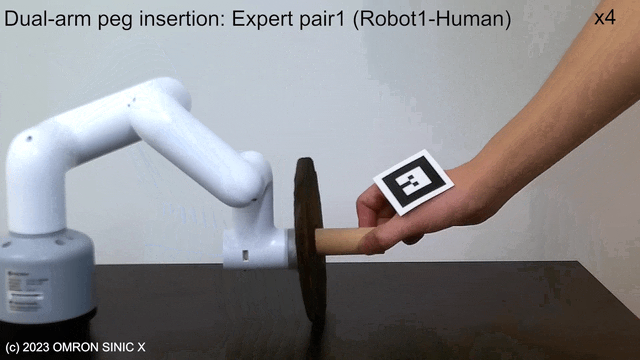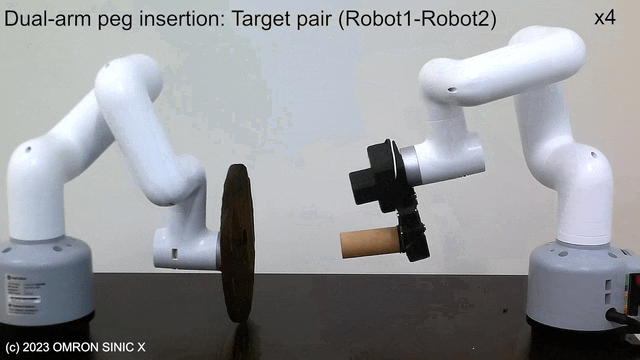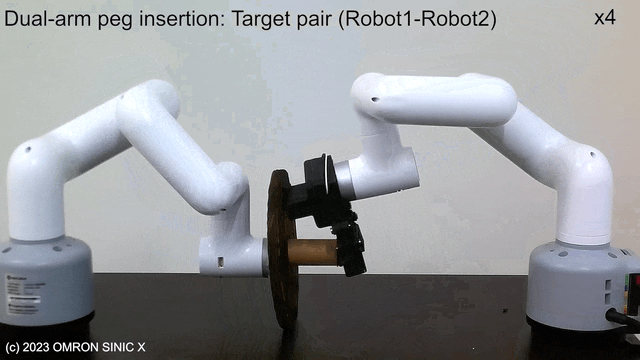
LfDT:Learning Dual-Arm Manipulation from Demonstration Translated from a Human and Robotic Arm
双腕協調タスクにおいて人間-ロボットのデモデータのペアからロボット-ロボットのデモデータへとDomain Translationし、模倣学習を行うフレームワークであるLfDTを提案.CycleGAN的にCross-Domain Correspondence.
Mixed Reality-based Robot Interface 2026
/
Preprint Paper
· Project
MR-GLi: Mixed Reality-Based Gripper-Linked Overlays for Underwater Robot Arm Teleoperation via Bilateral Control
水中ロボットアームの遠隔操作において、反力トルクインジケーターと手首カメラ映像をグリッパに空間的に紐づけて提示するMRインタフェース.20名の被験者内比較で、トルク調整性能・作業負荷・使いやすさを維持したまま、視線移動の負担を有意に低減.
2026
/
IEEE IROS Paper
· Project
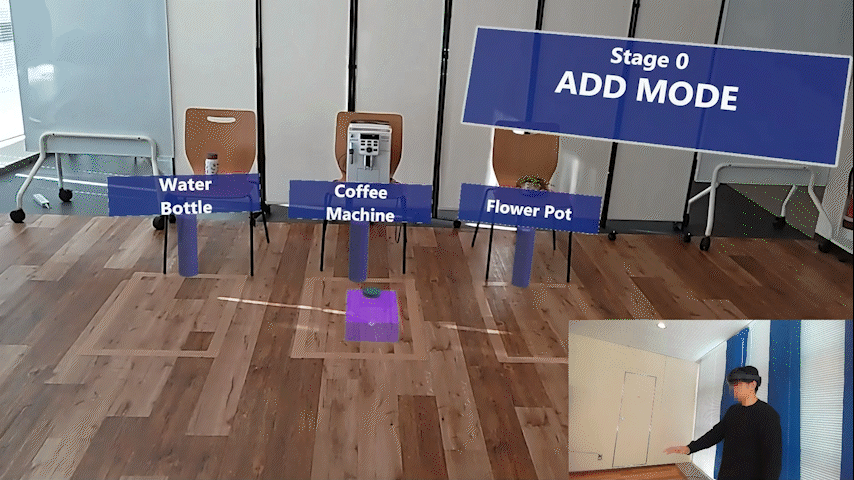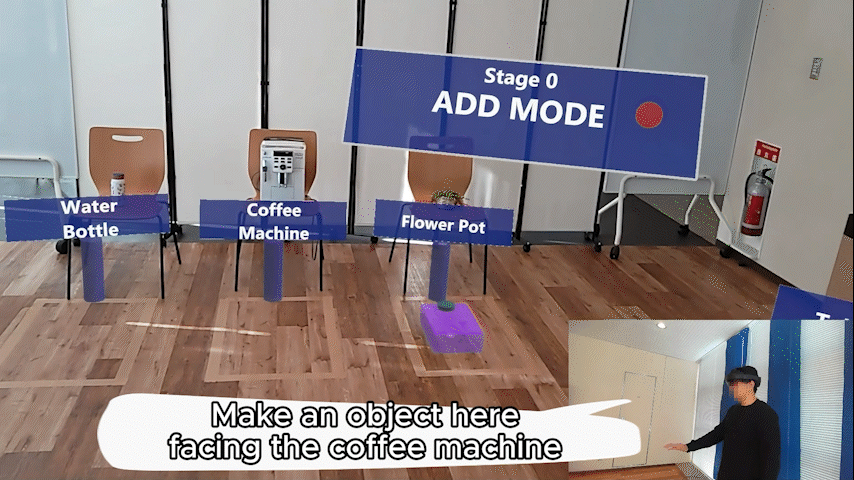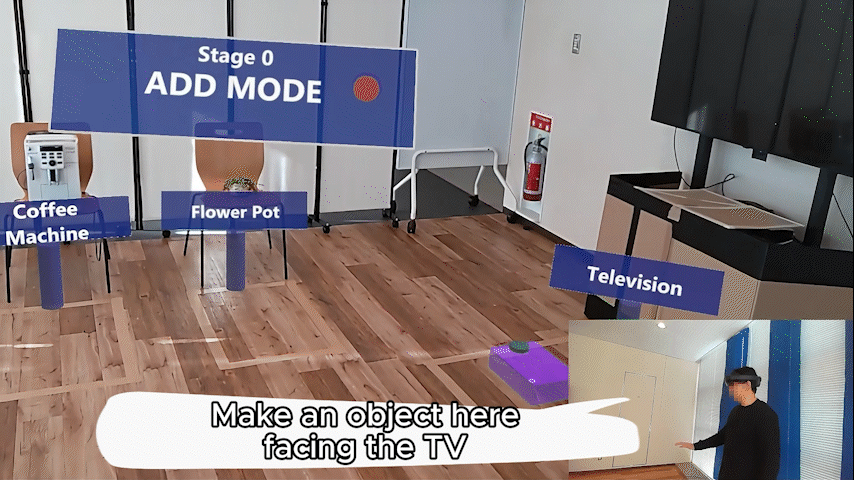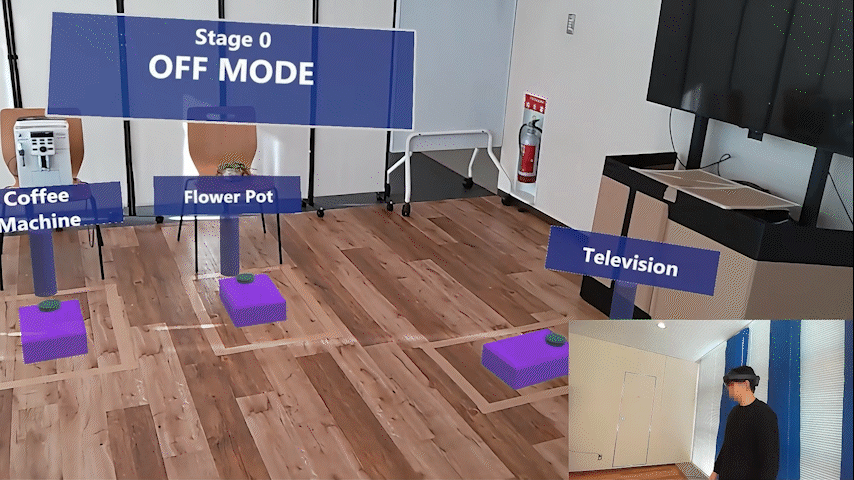
Mixed Reality-Based Robot Navigation Interface Using Spatial Pointing and Speech with Large Language Model
複雑なハンドジェスチャーの代わりに、空間ポインティング(指さし)とLLMベースの音声対話を組み合わせたマルチモーダルな移動ロボットMRインタフェース.従来のジェスチャー型MRインタフェースと比較して、タスク完了時間と負荷を有意に低減する.
2026
/
IEEE RO-MAN
Video Friday Paper
· Project
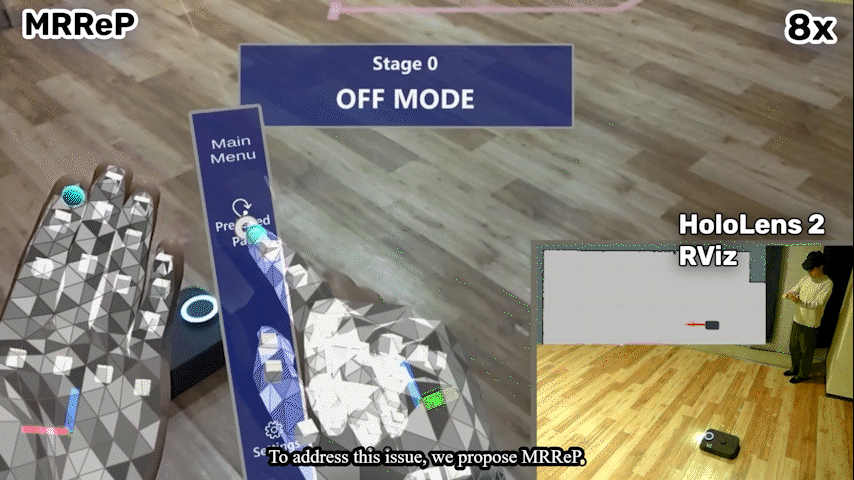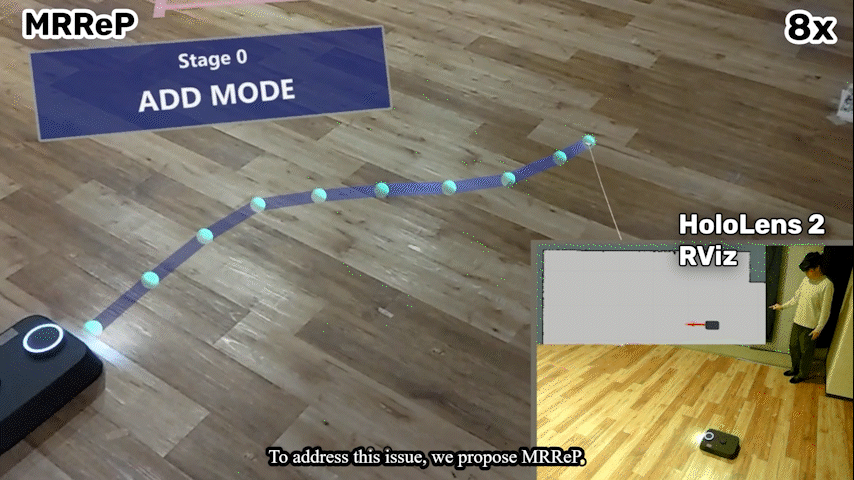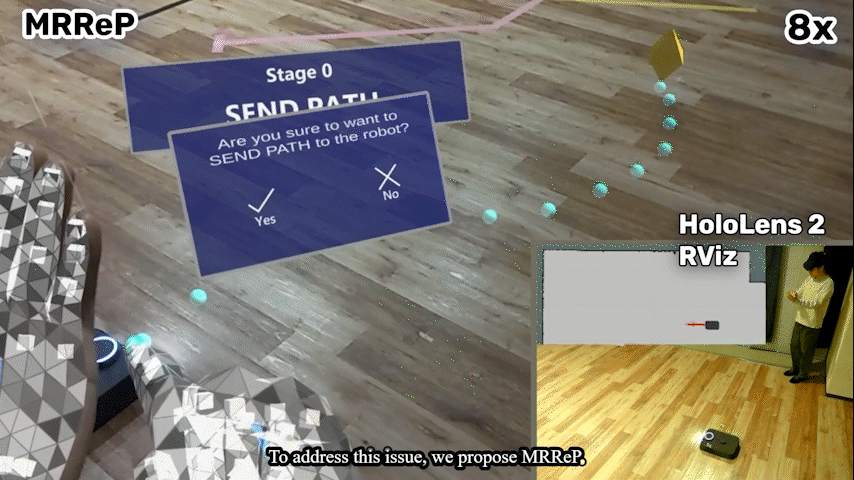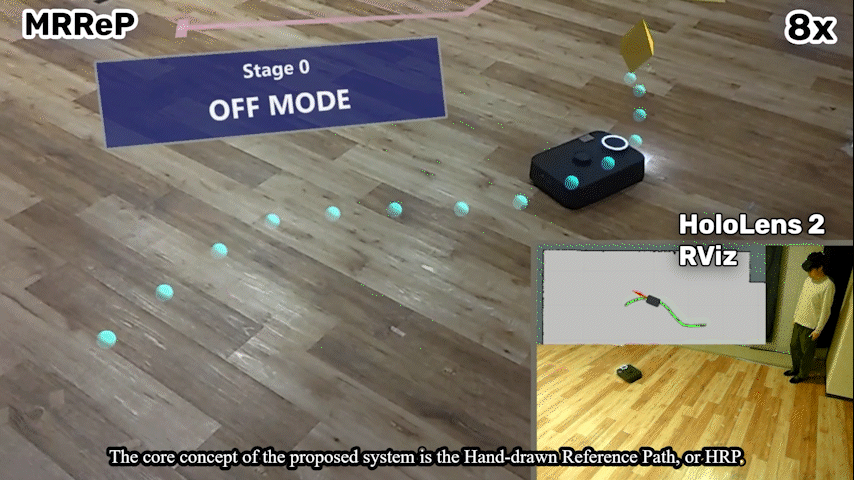
MRReP: Mixed Reality-based Hand-drawn Reference Path Editing Interface for Mobile Robot Navigation
複合現実(MR)上で床面に手描き参照経路(HRP: Hand-drawn Reference Path)を描き、カスタムプランナで ROS 2 ナビゲーションスタックに組み込んで自律走行させる移動ロボット向けインタフェース.2D マップ上の従来インタフェースとの被験者内比較で、経路指定精度・使いやすさ・主観的負荷の改善と、実空間におけるより安定した経路指定を実現.
2026
/
IEEE Access Paper
· Project
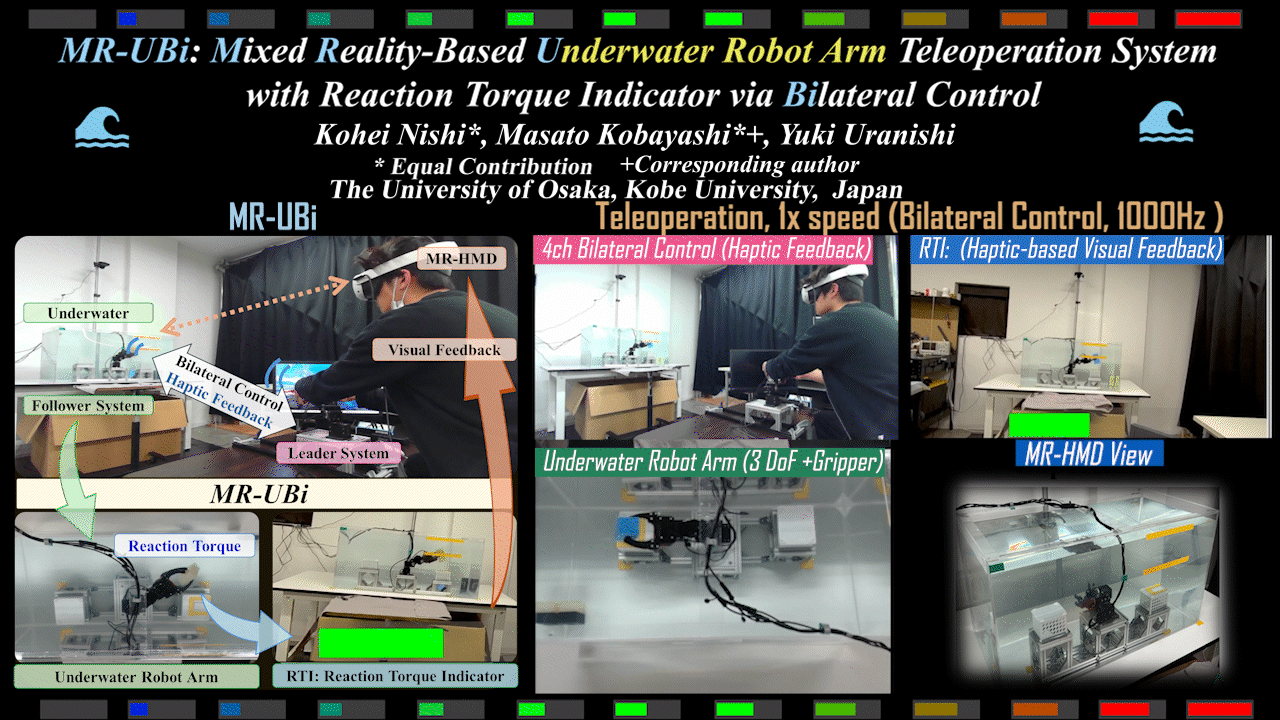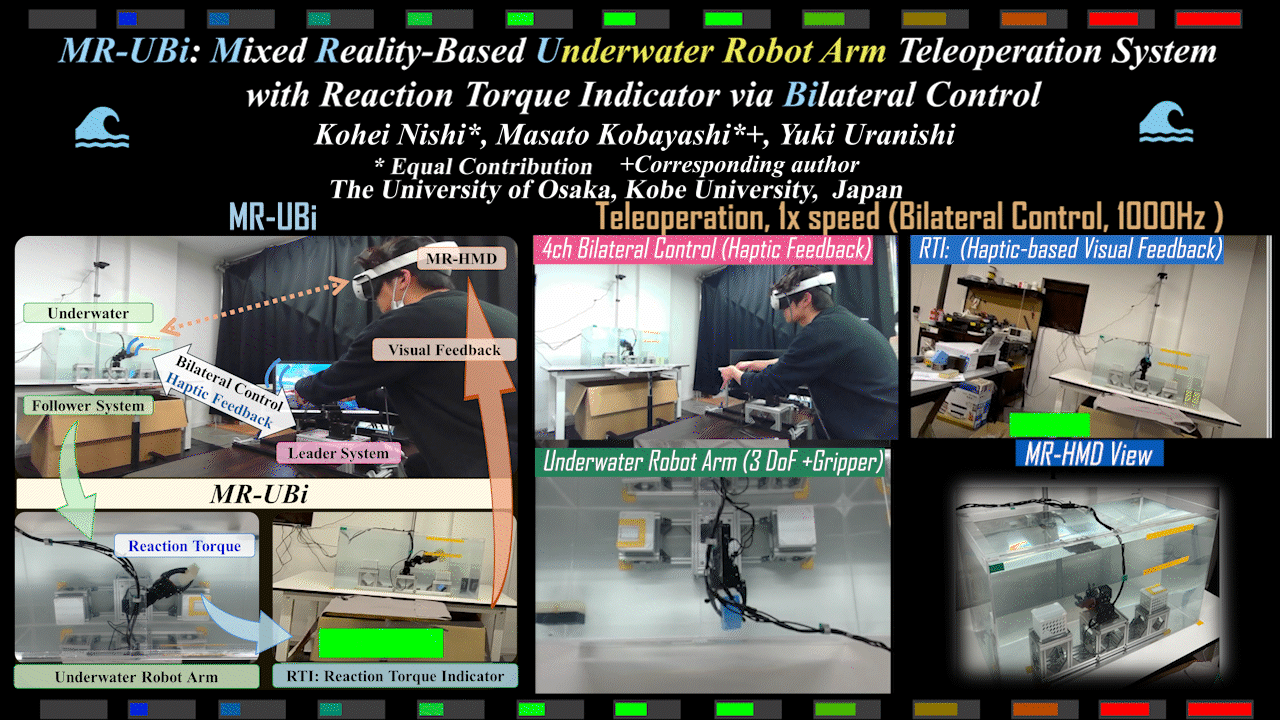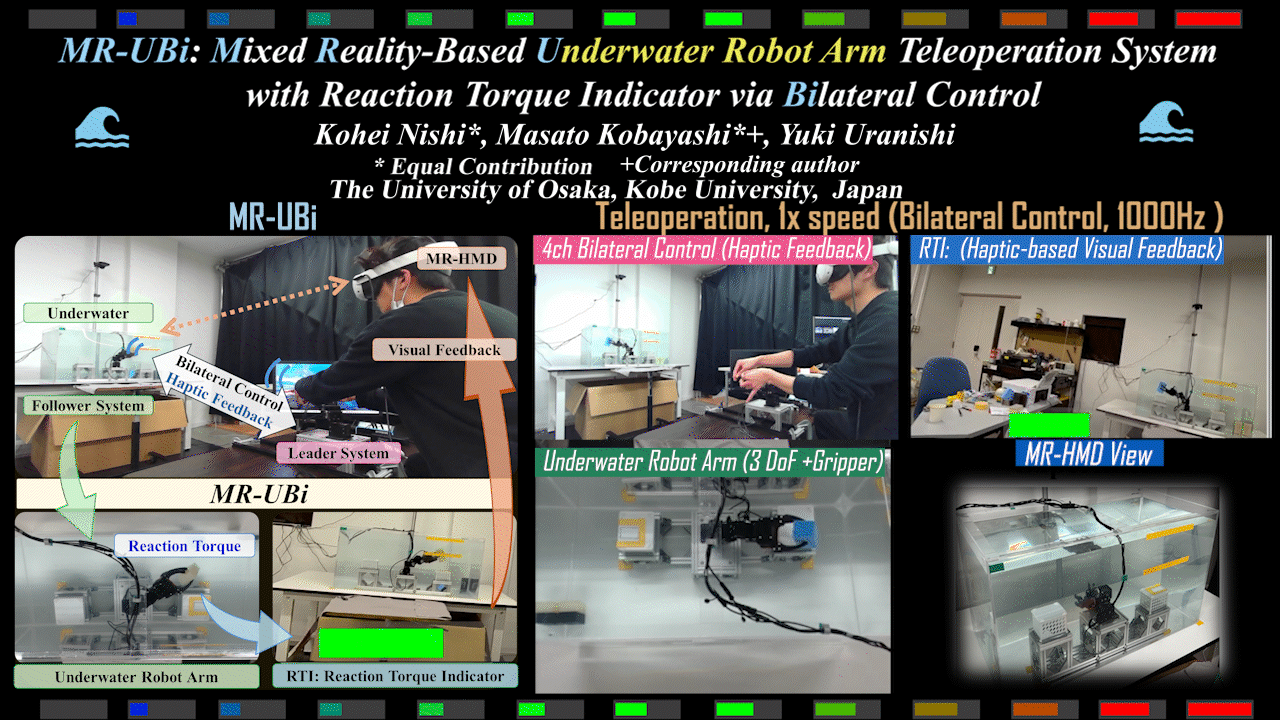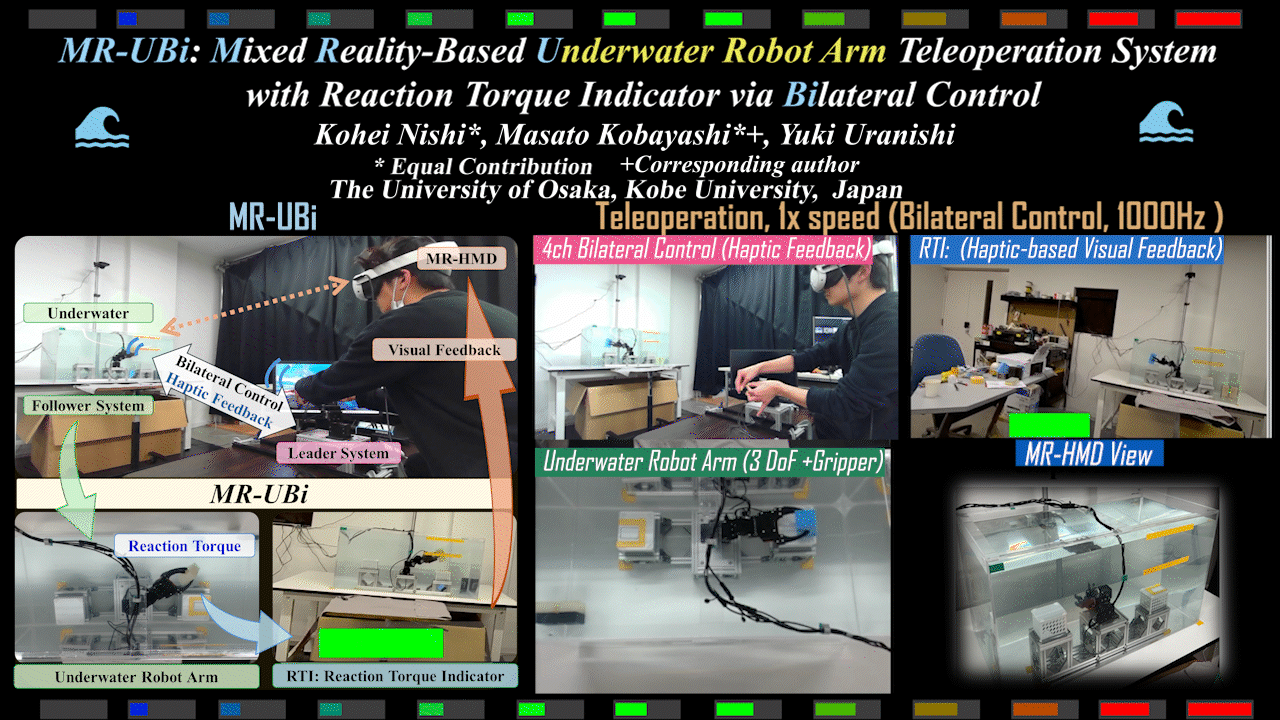
MR-UBi: Mixed Reality-Based Underwater Robot Arm Teleoperation System with Reaction Torque Indicator via Bilateral Control
水中において反力トルクインジケーターを備えた複合現実(MR: Mixed Reality)ベースの水中ロボットアーム遠隔操作システム.バイラテラル制御による直感的な操作を実現.
2025
/
IEEE RO-MAN
Video Friday Paper
· Project
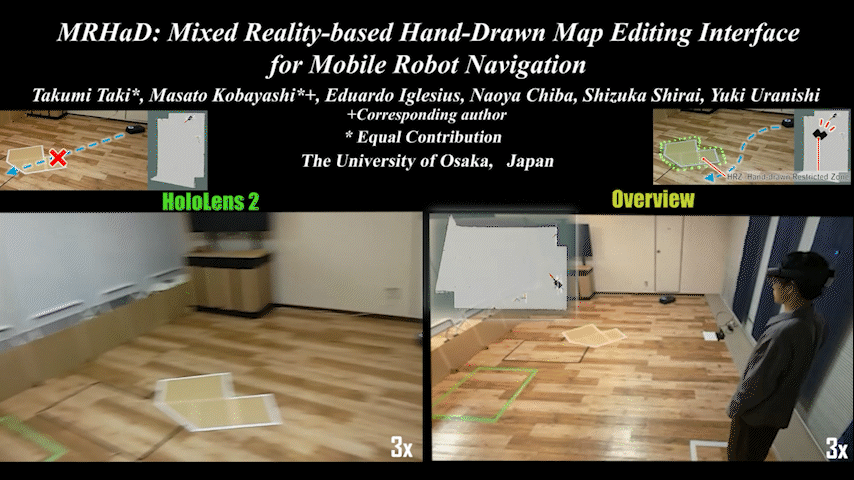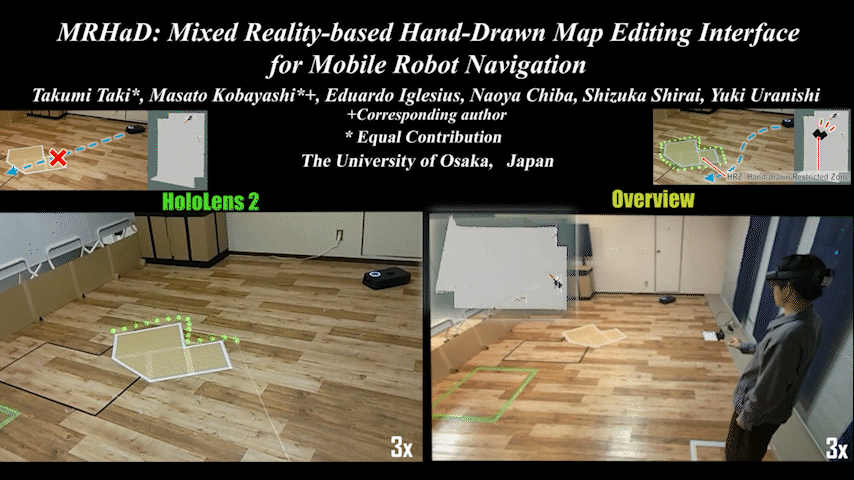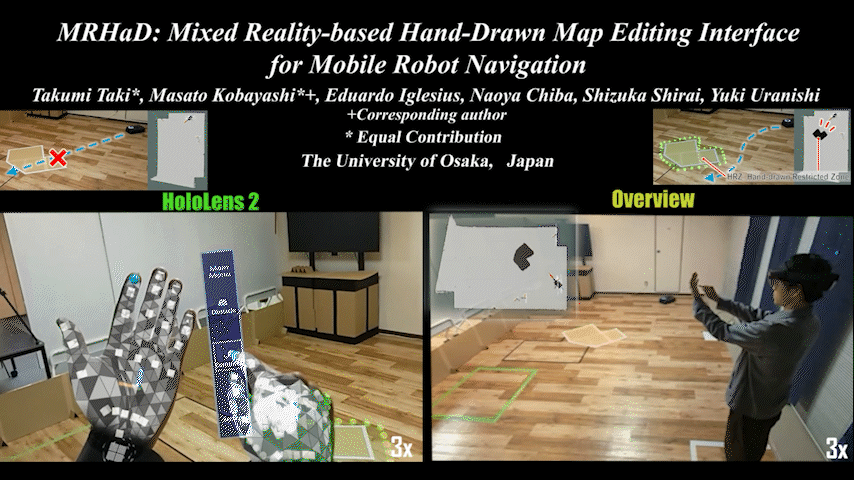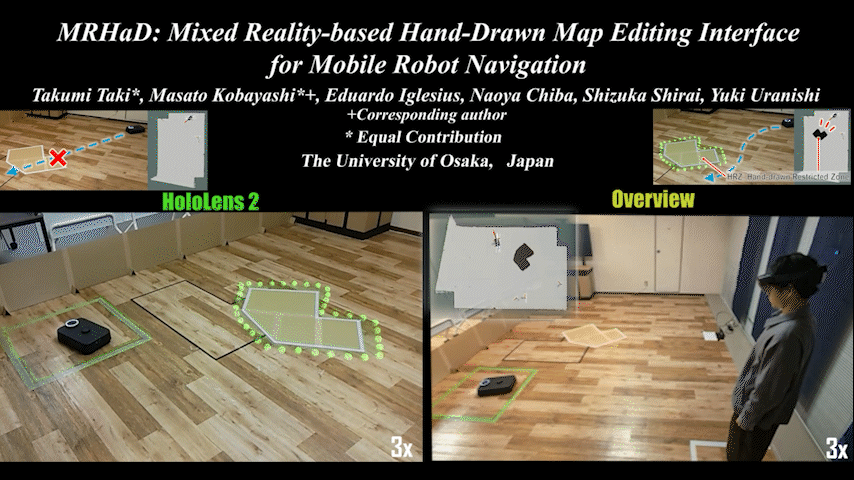
MRHaD: Mixed Reality-based Hand-Drawn Map Editing Interface for Mobile Robot Navigation
手描きマップ編集インターフェースを備えた複合現実(MR: Mixed Reality)ベースのモバイルロボットナビゲーションシステム.直感的な地図編集を実現.
2024
/
Advanced Robotics Paper
· Project
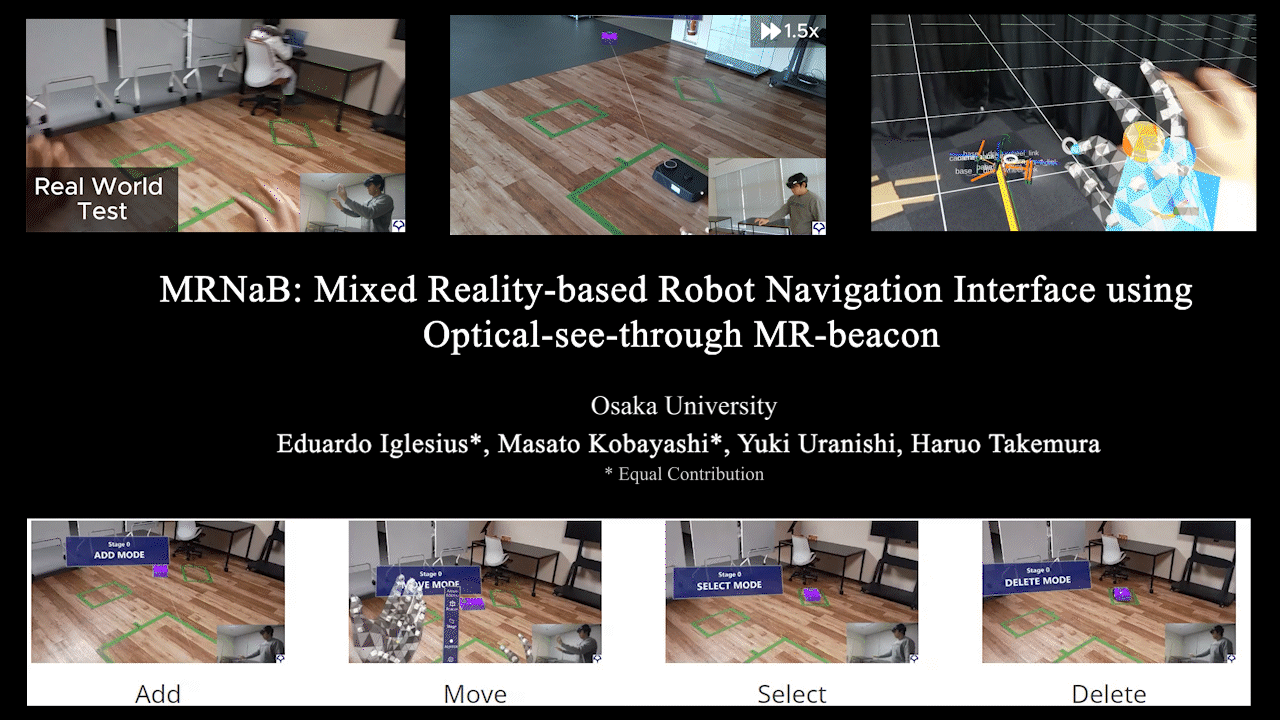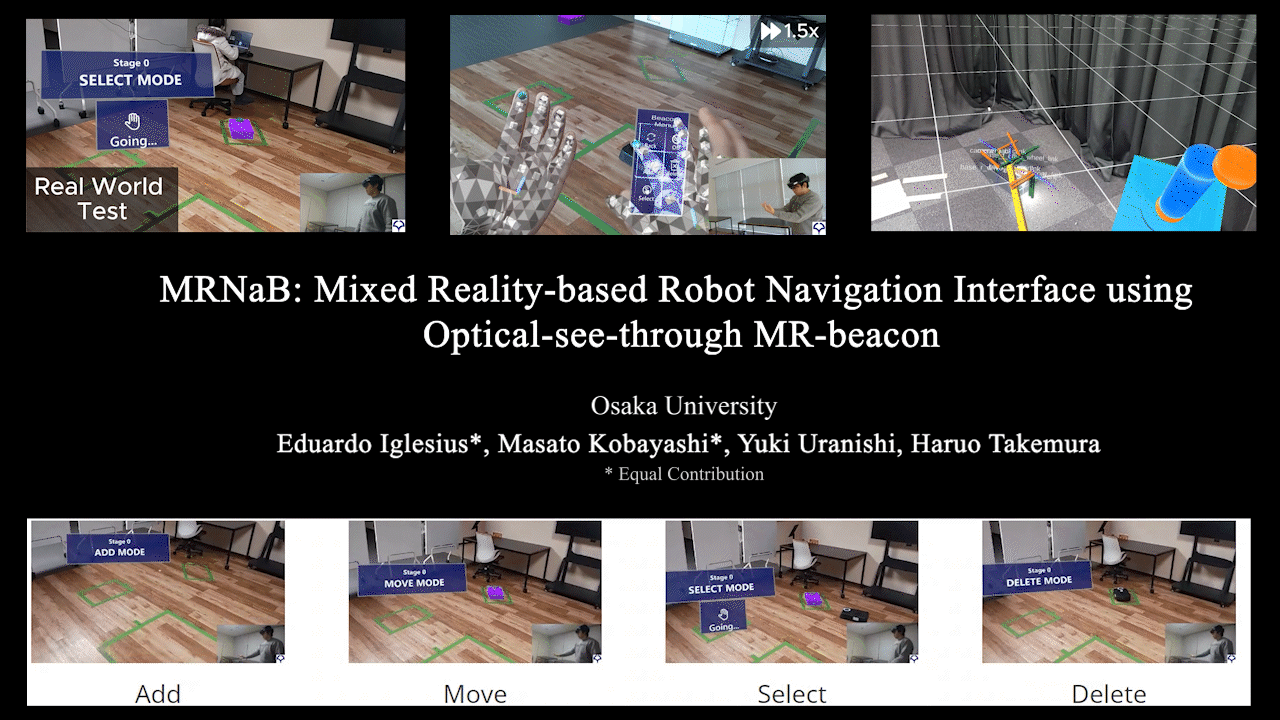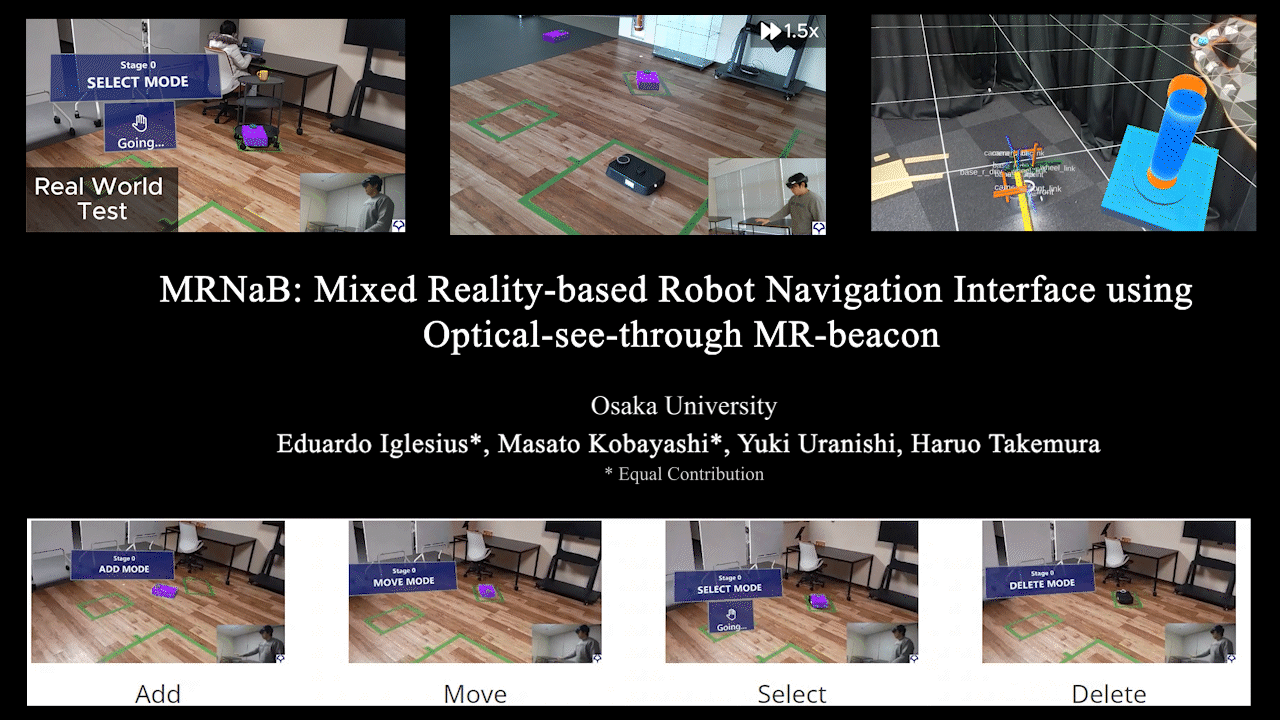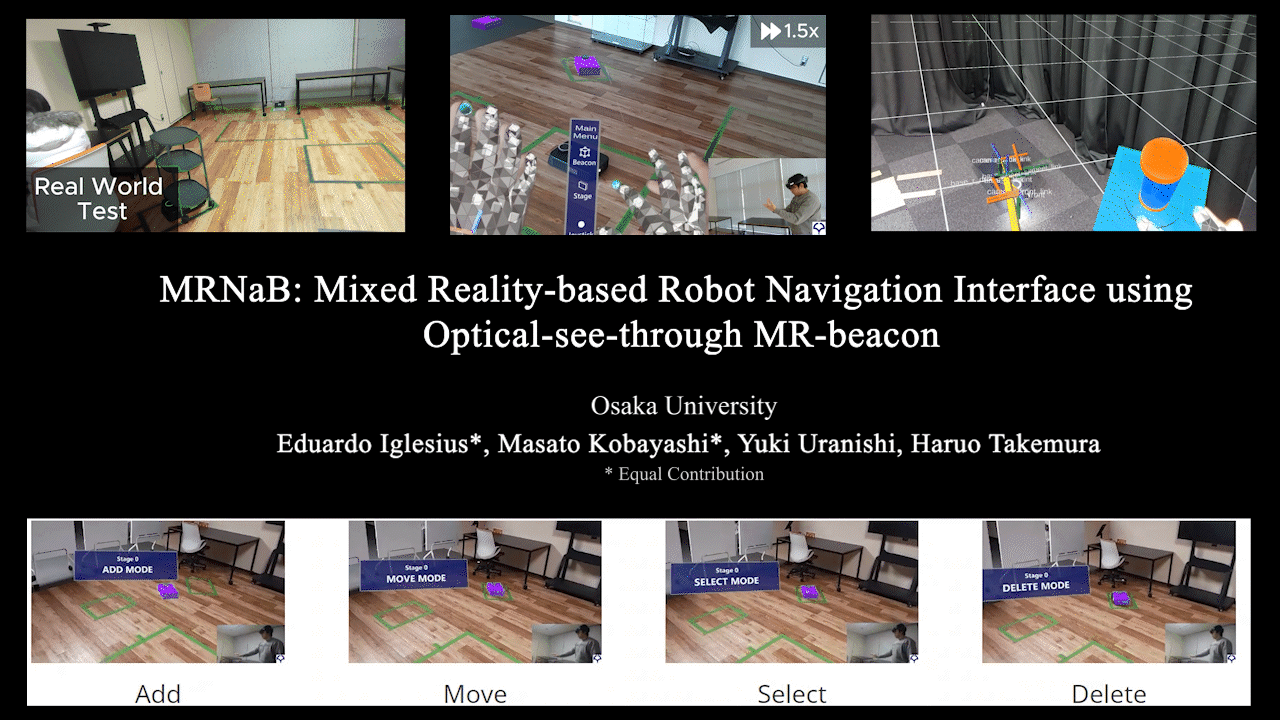
MRNaB: Mixed Reality-based Robot Navigation Interface using Optical-see-through MR-beacon
複合現実(MR: Mixed Reality)ベースのロボットナビゲーションインターフェース.実世界とVirtual空間の融合によるナビゲーションを実現.
Legged Robot Learning 2026
/
Tool
Video Friday Project
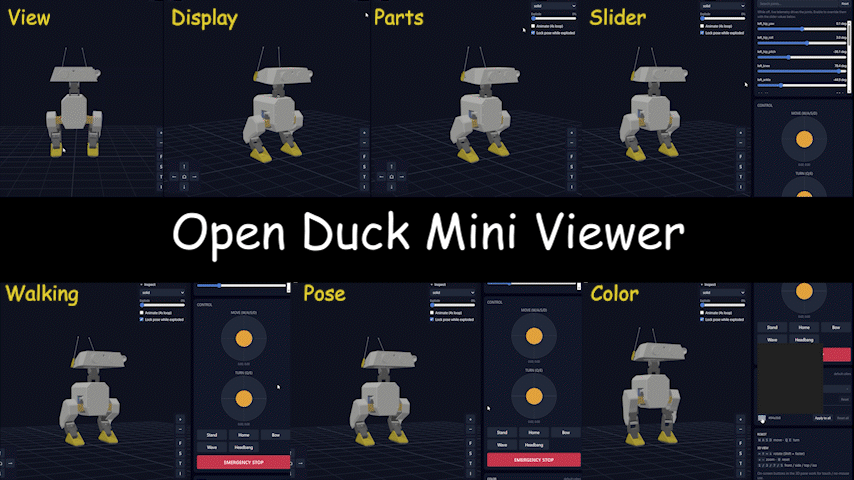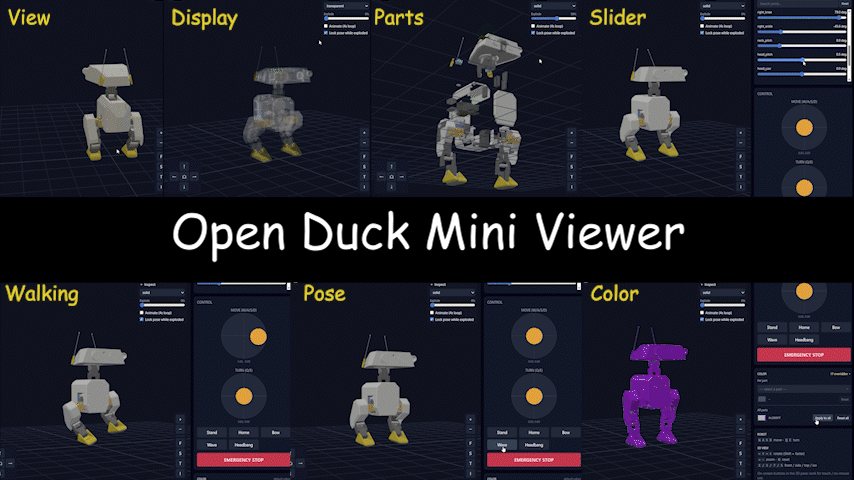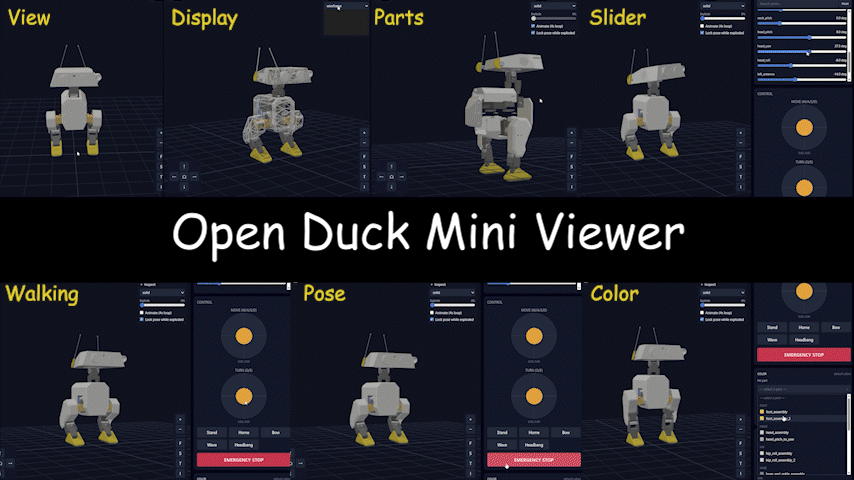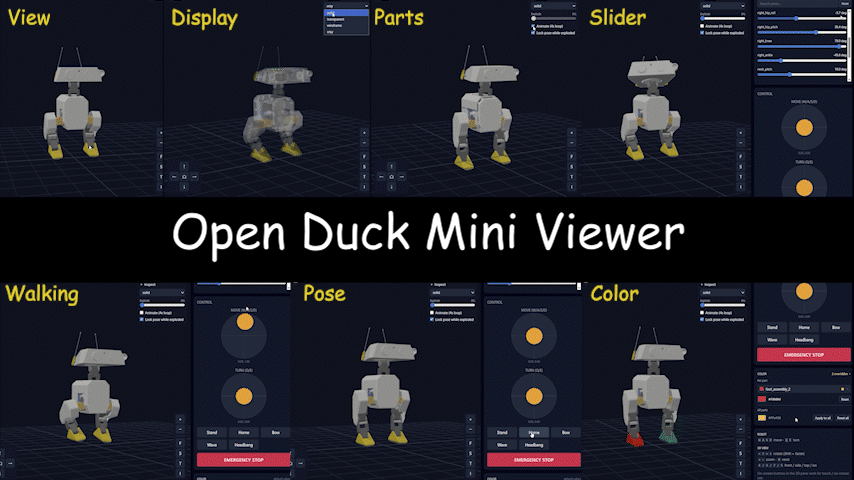
Web-based Real-time Visualization Tool for Open Duck Mini Bipedal Robot
低コスト二足歩行ロボット Open Duck Mini 向けの、Web ブラウザ上で動作する可視化ツール.
2026
/
IEEE RO-MAN
Video Friday Project
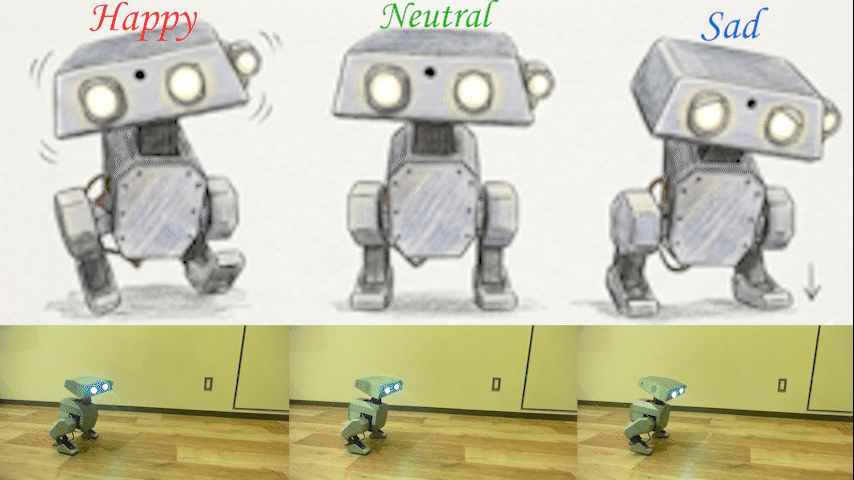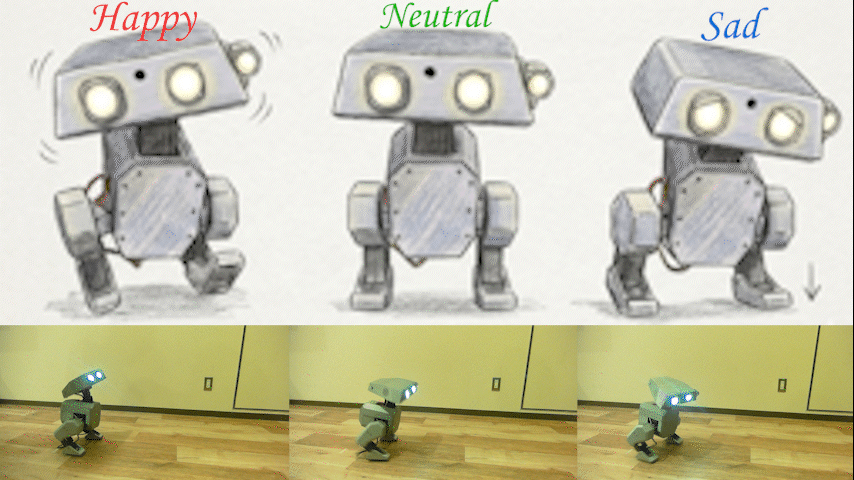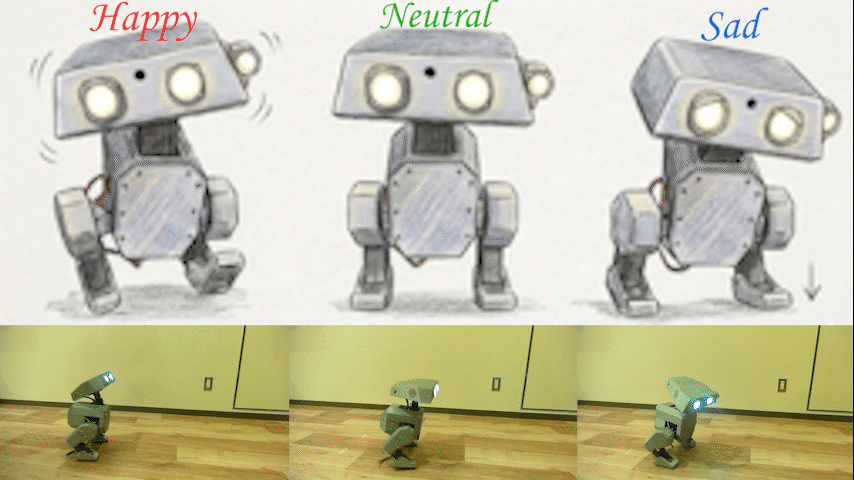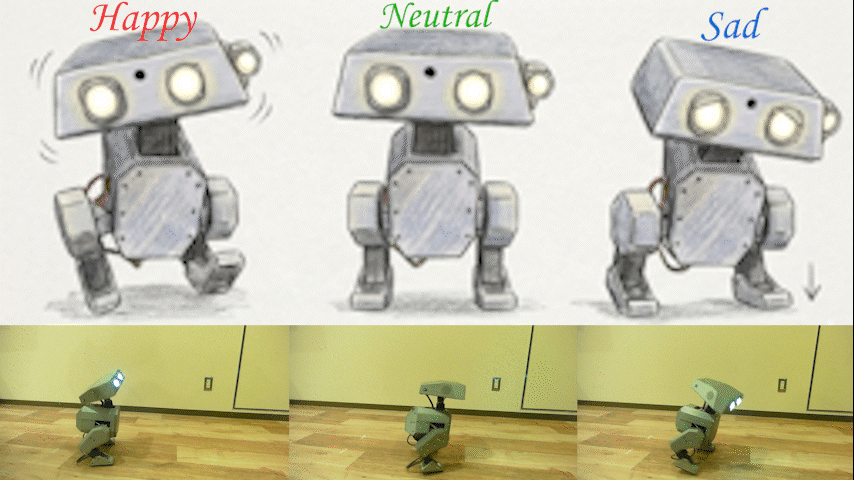
EmoLo: Emotion-Inspired Expressive Locomotion via Single-Policy Reinforcement Learning on Low-Cost Bipedal Robots
低コスト二足歩行ロボット Open Duck Mini V2 向けの、スタイル条件付き強化学習による感情に着想を得た表現的歩行.Happy / Neutral / Sad の3スタイルを単一ポリシーで切り替え、sim-to-real(ONNX 実機推論)を実現.
2026
/
Preprint Project
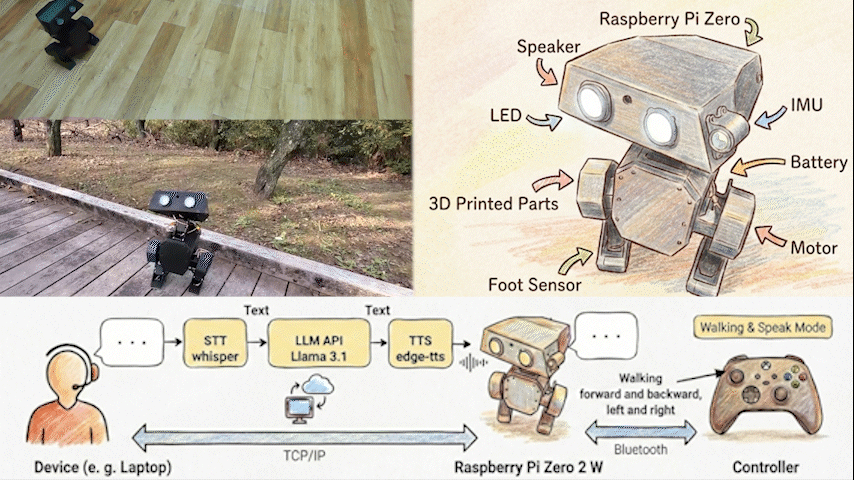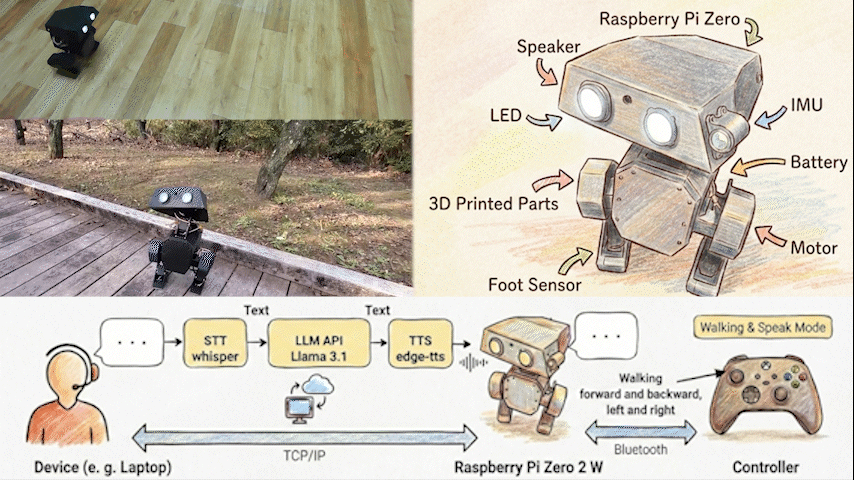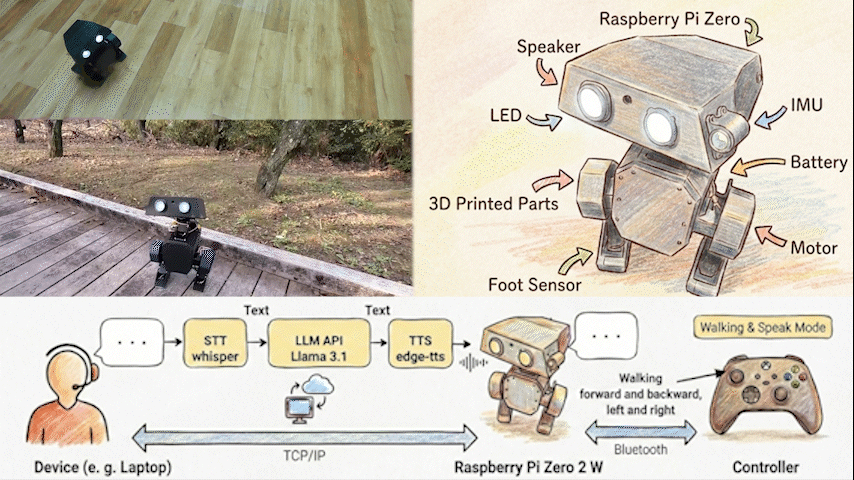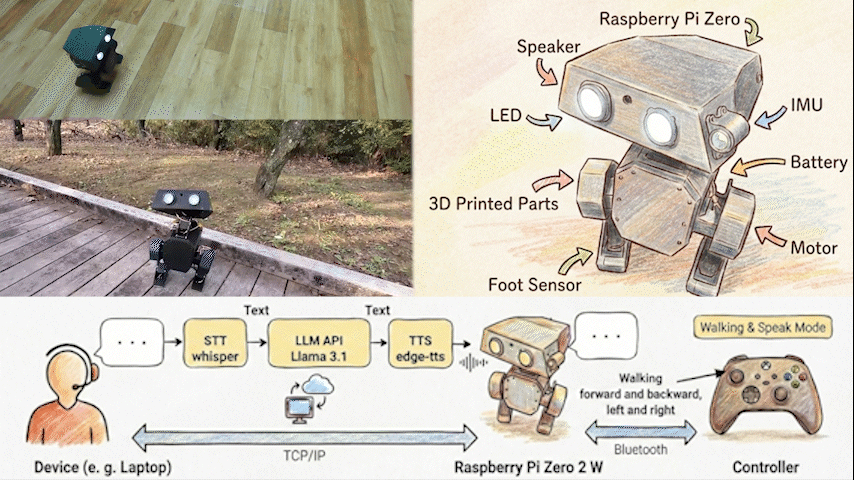
SpeeLo: Speech Interaction During Locomotion in Resource-Constrained Bipedal Robot
計算資源が限られた二足歩行ロボット(Open Duck Mini)で、歩行中の音声対話を両立するためのアーキテクチャ.
2026
/
Demo Project
Compact BDX-style Bipedal Droid Demo
小型 BDX スタイル二足歩行ドロイドの動作デモ.Open Duck Mini プラットフォームを用いた歩行・動作の実機実装.
2025
/
Demo Project
Open Duck Mini Holiday Motion Demo
Open Duck Mini を用いたホリデーシーズン向けの動作デモ.
Underwater Robots 2026
/
Preprint
Video Friday Paper
· Project
ULOHA: An Underwater Bimanual Robot System for Robot Learning
独自のリーダー・フォロワー機構と、LeRobotを水中双腕ロボット向けに拡張したソフトウェアにより、遠隔操作・実演データ収集・自律実行を統合したロボット学習プラットフォーム。9種類の水中タスクでACTを評価し、選択したタスクではDiffusion PolicyとSmolVLAの水中実機への適用も検証。浮力を利用した操作、気泡の影響、動作実行のタイミング、SmolVLAのReal-Time Chunking(RTC)、空中・水中間の転移も評価。ハードウェア設計とソフトウェアはオープンソースとして公開予定。
2026
/
IEEE IROS
Video Friday Paper
· Project
Bi-AQUA: Bilateral Control-Based Imitation Learning for Underwater Robot Arms via Lighting-Aware Action Chunking with Transformers
世界初の水中バイラテラル制御に基づく模倣学習を実世界で実現.水中・水上の画像・照明・位置・力情報に基づくロボット学習モデルと位置・力制御による自律動作
2026
/
Preprint Paper
· Project
MR-GLi: Mixed Reality-Based Gripper-Linked Overlays for Underwater Robot Arm Teleoperation via Bilateral Control
水中ロボットアームの遠隔操作において、反力トルクインジケーターと手首カメラ映像をグリッパに空間的に紐づけて提示するMRインタフェース.20名の被験者内比較で、トルク調整性能・作業負荷・使いやすさを維持したまま、視線移動の負担を有意に低減.
2026
/
IEEE Access Paper
· Project
MR-UBi: Mixed Reality-Based Underwater Robot Arm Teleoperation System with Reaction Torque Indicator via Bilateral Control
水中において反力トルクインジケーターを備えた複合現実(MR: Mixed Reality)ベースの水中ロボットアーム遠隔操作システム.バイラテラル制御による直感的な操作を実現.
Autonomous Mobile Robot 2026
/
Preprint Paper
· Project
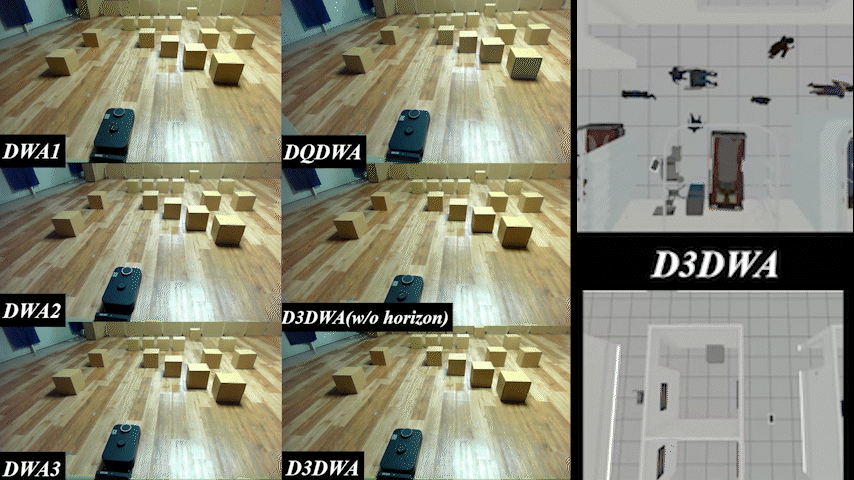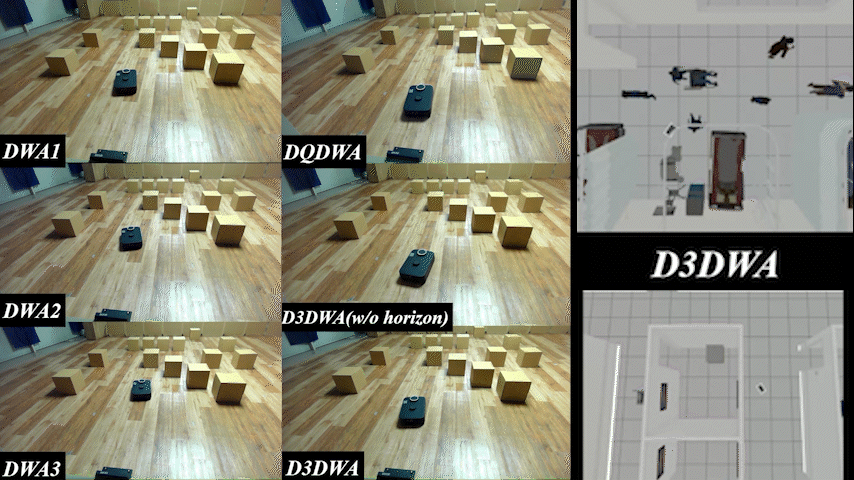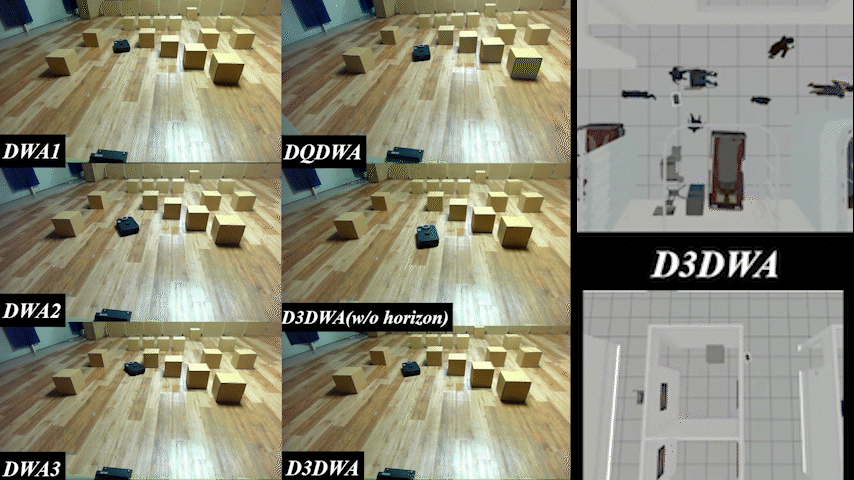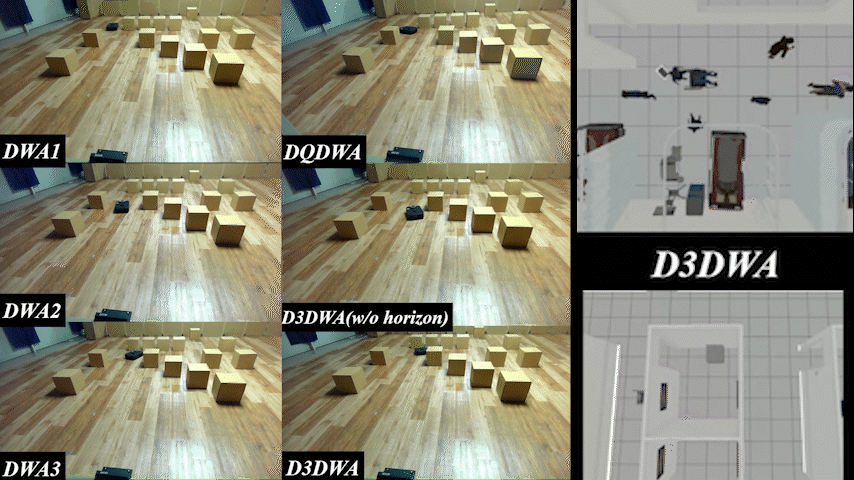
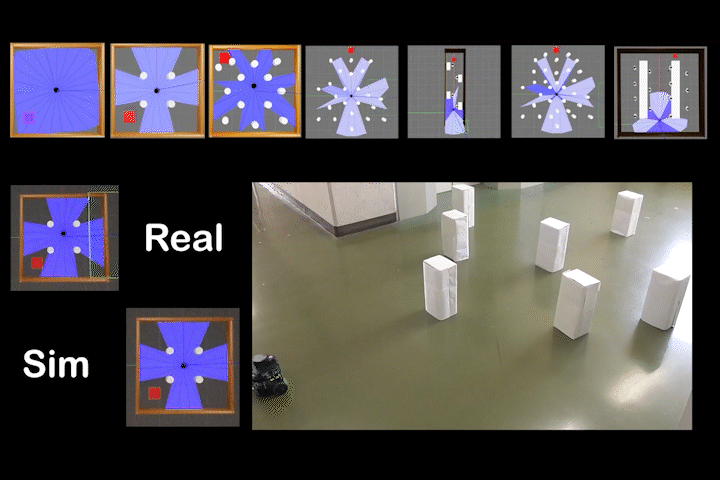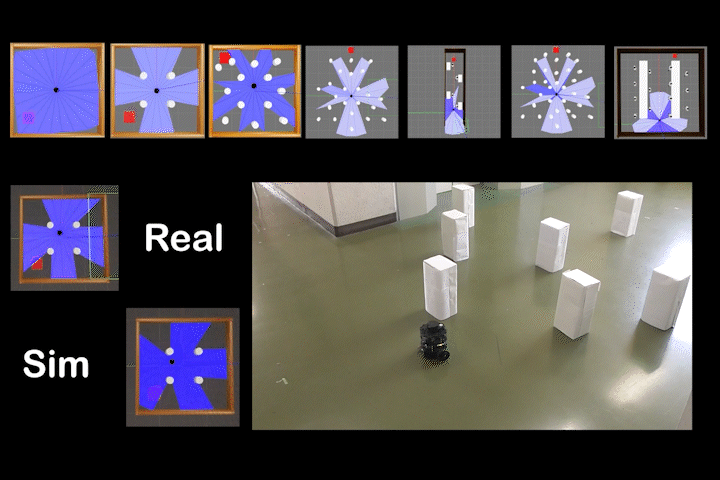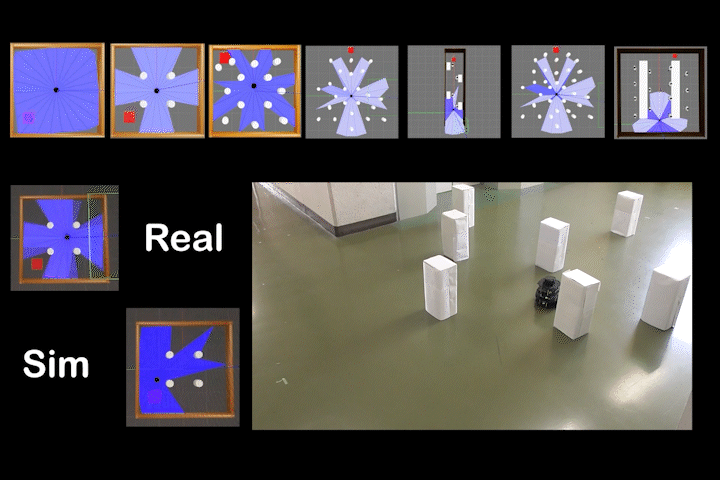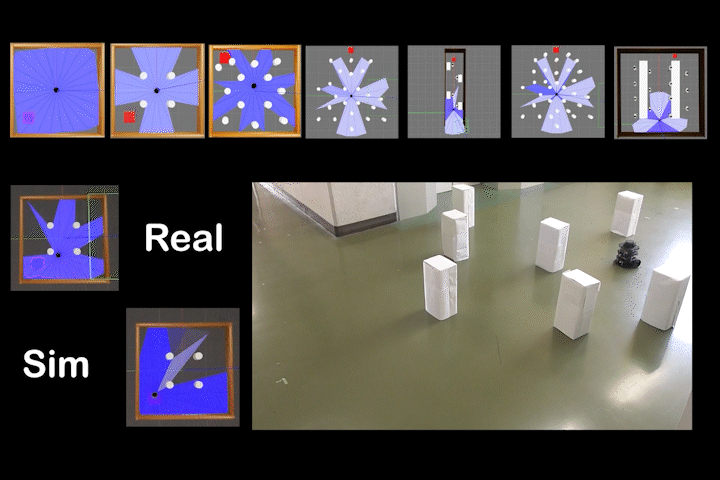
D3DWA: Adaptive Weight and Prediction-Horizon for Dynamic Window Approach via Dueling Double Deep Q-Network
Dueling Double Deep Q-Network により、DWAの評価重みと予測ホライズンを制御周期ごとに同時に選択する適応的局所経路計画.8つのシミュレーション環境と3つの実機構成のすべてでゴールに到達.
2023
/
IEEE Transactions IA Paper
· Project
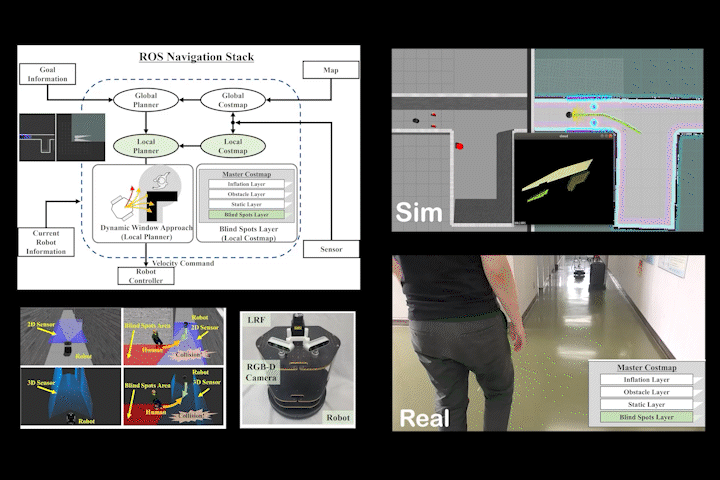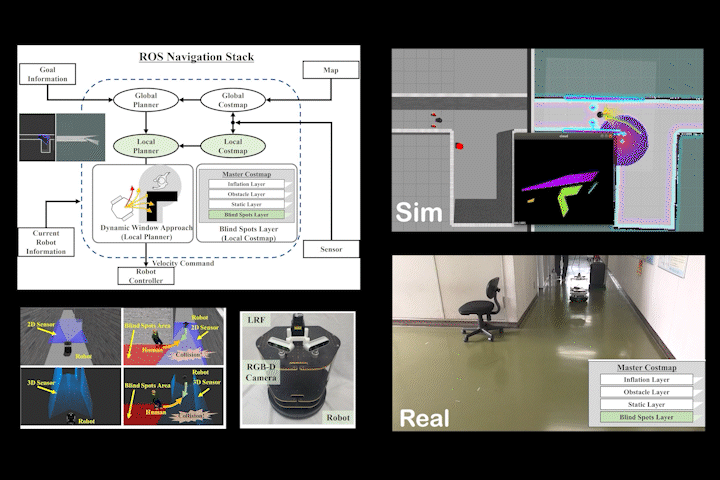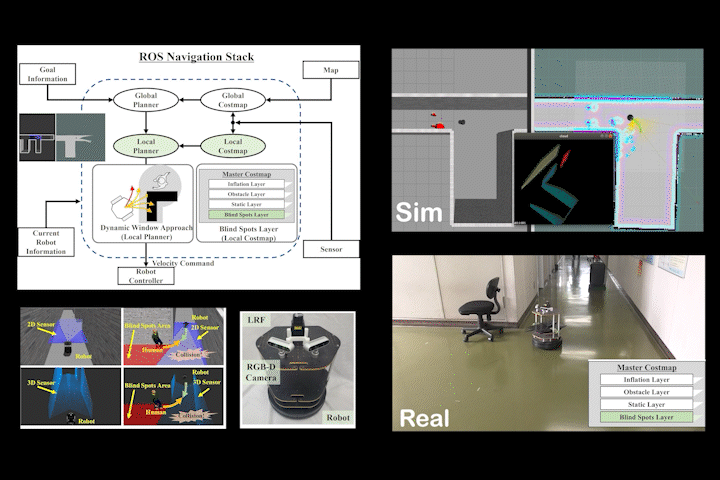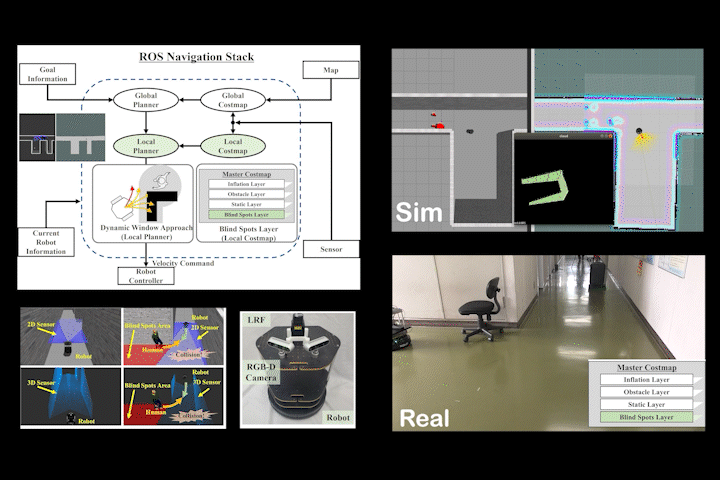
BSL: Navigation Method Considering Blind Spots Based on ROS Navigation Stack and Blind Spots Layer for Mobile Robot
ROS Navigation StackとBlind Spots Layerに基づく、センサ死角を考慮したモバイルロボットのナビゲーション手法.
2023
/
IEEE Access Paper
· Project
DQDWA: Local Path Planning: Dynamic Window Approach With Q-Learning Considering Congestion Environments for Mobile Robot
強化学習(Q-Learning)に基づく動的なDWAのパラメータ調整による、混雑環境を考慮したモバイルロボットの局所経路計画.
2022
/
IEEE Access Paper
· Project
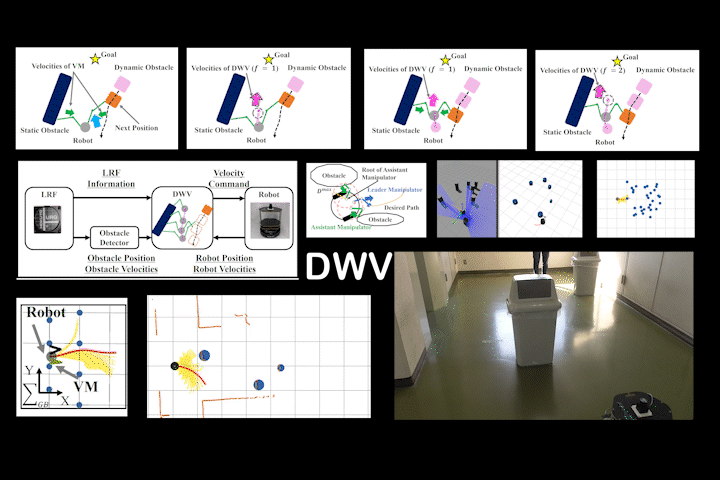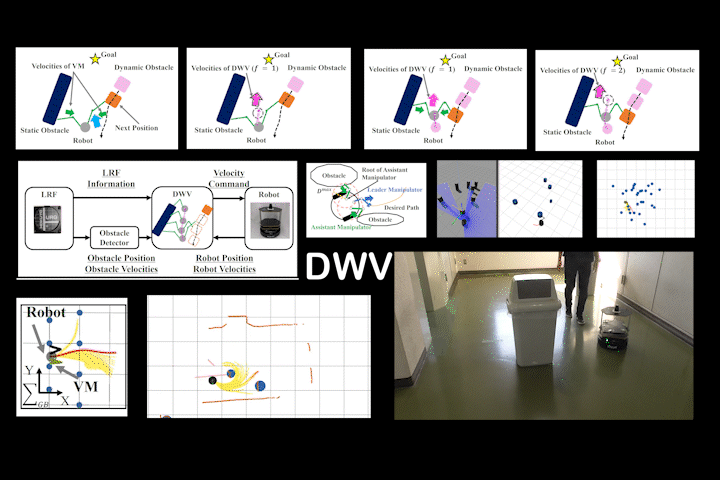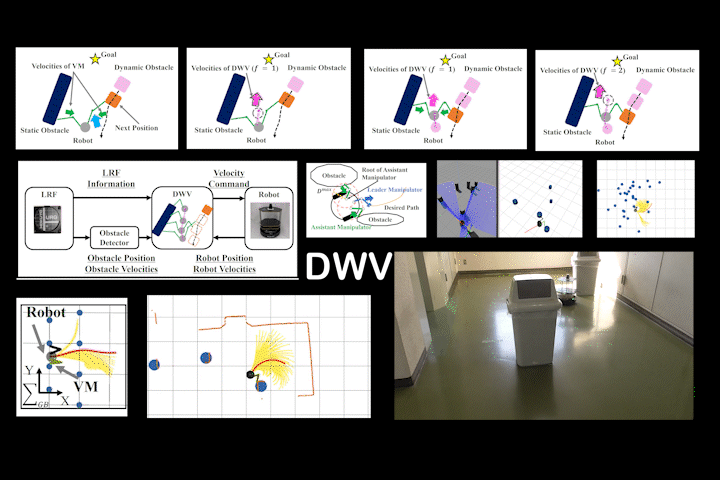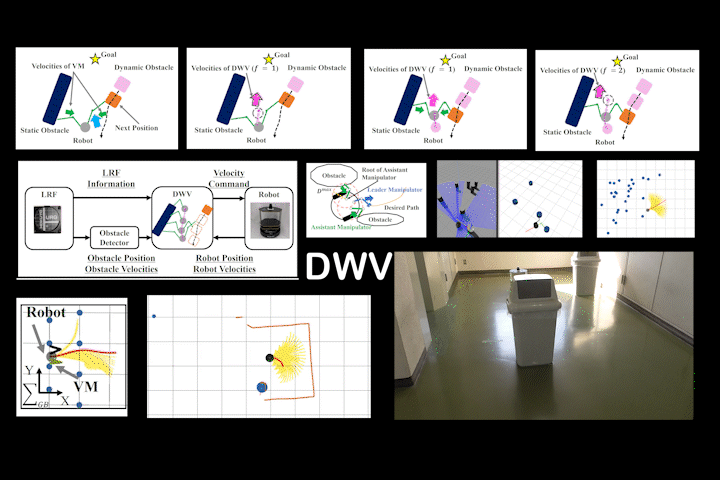
DWV: Local Path Planning: Dynamic Window Approach With Virtual Manipulators Considering Dynamic Obstacles
動的障害物を考慮した仮想マニピュレータを用いたDWAによる局所経路計画.動的環境での安全なナビゲーションを実現.
Robotics Learning Materials Project
二足歩行ロボットができるまでを60秒で紹介
Open Duck Mini V2の製作過程を60秒にまとめた動画.二足歩行ロボットの組み立てから完成までを紹介.
Project
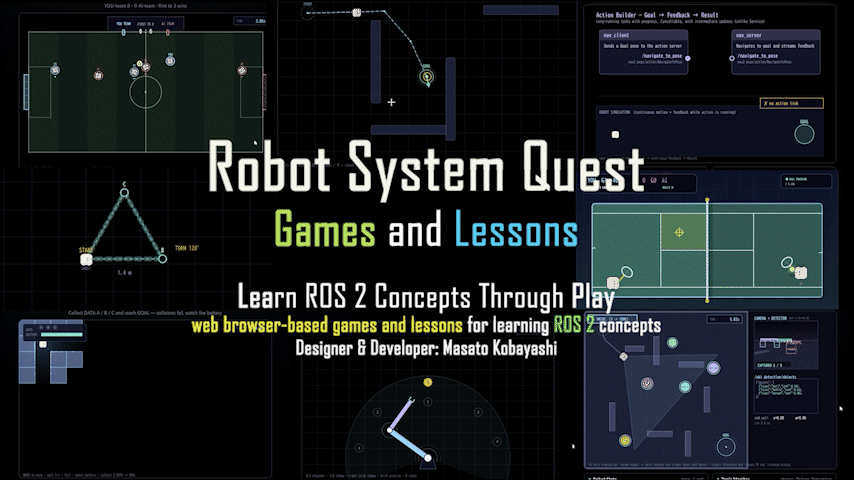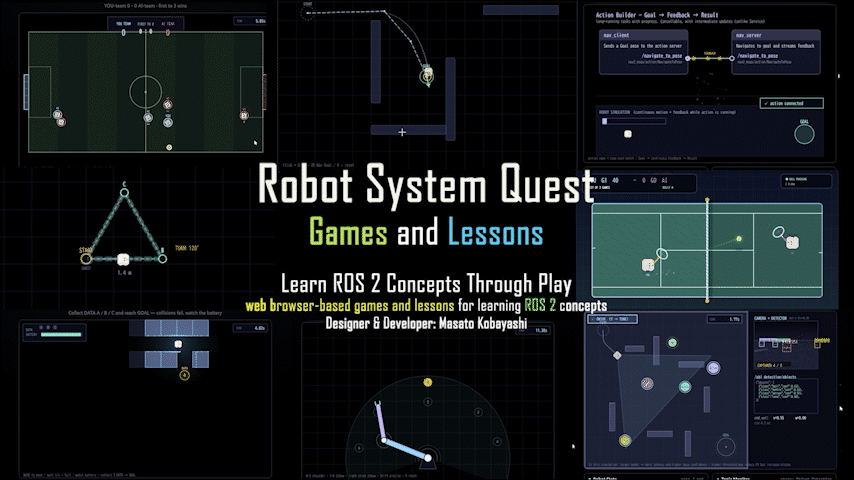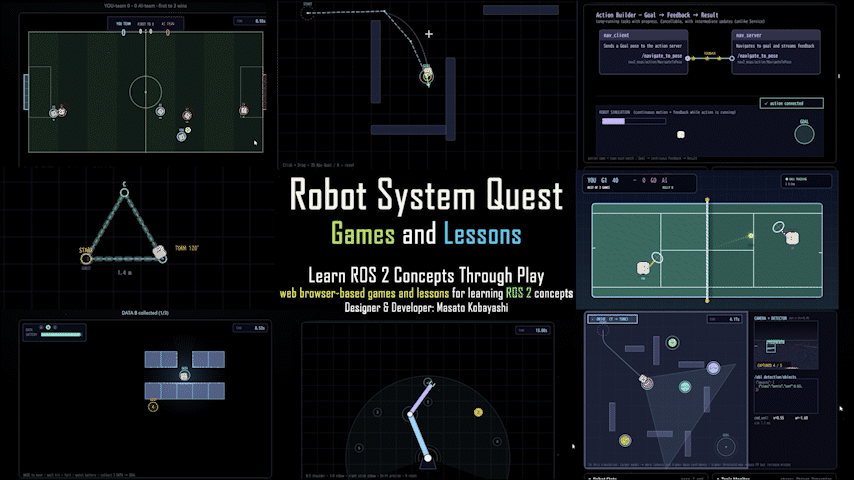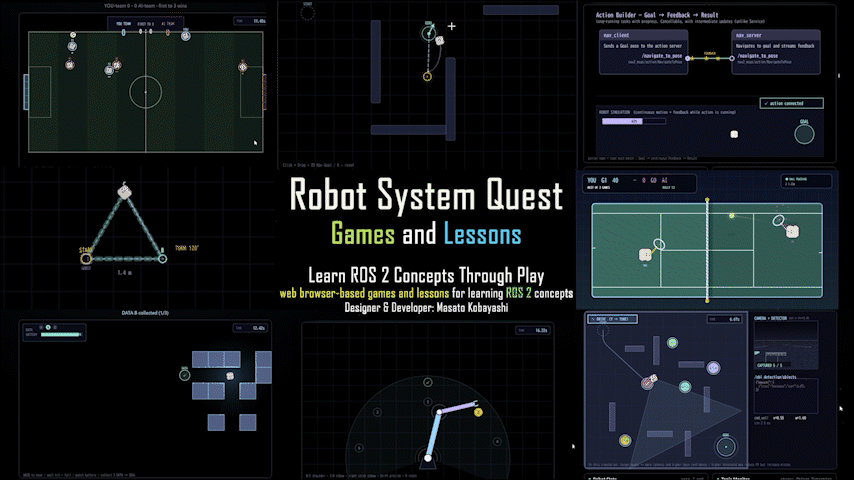
ブラウザで学ぶロボットシステムのゲーム・レッスン教材
ロボットを動かしながらROS 2の概念を学べる、ブラウザ完結のゲーム・レッスン教材.日本語・英語に対応.
Project
Webブラウザで二足歩行ロボットを操作できる体験型教材
Webブラウザから誰でも二足歩行ロボット Open Duck Mini を操作できるインタフェース.ロボットの動きを見ながら体験的に学べる.
Project
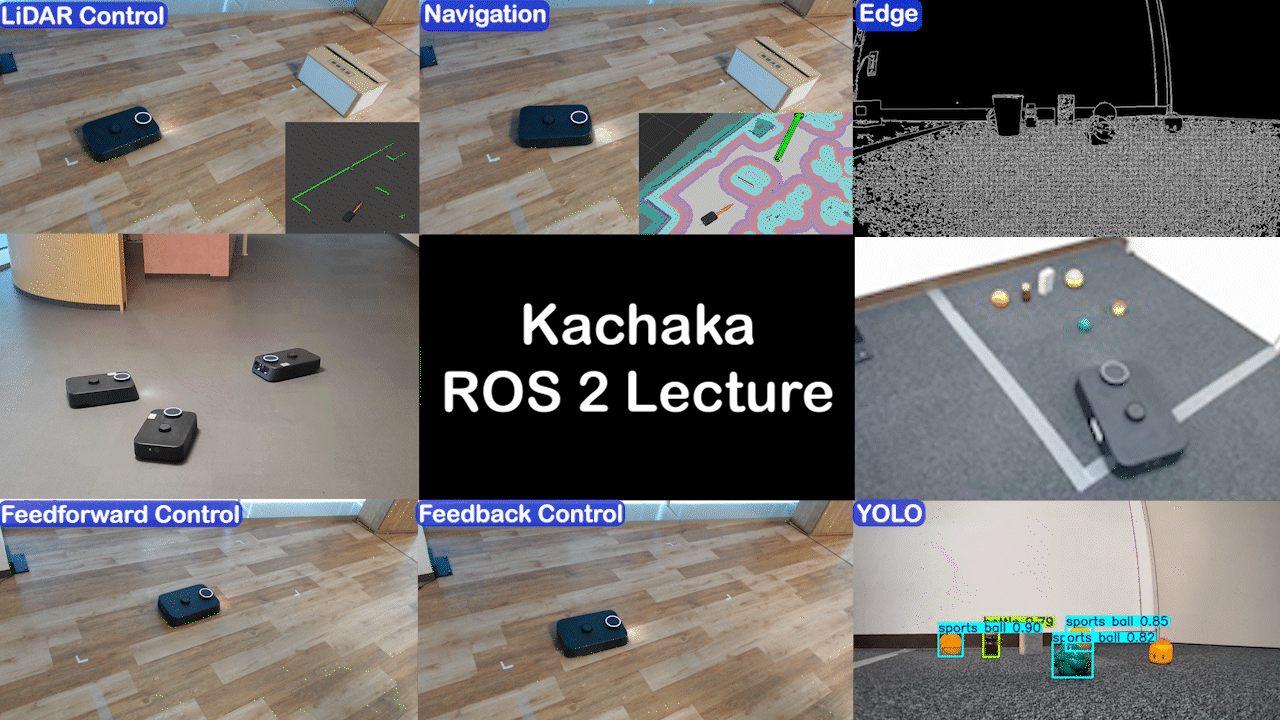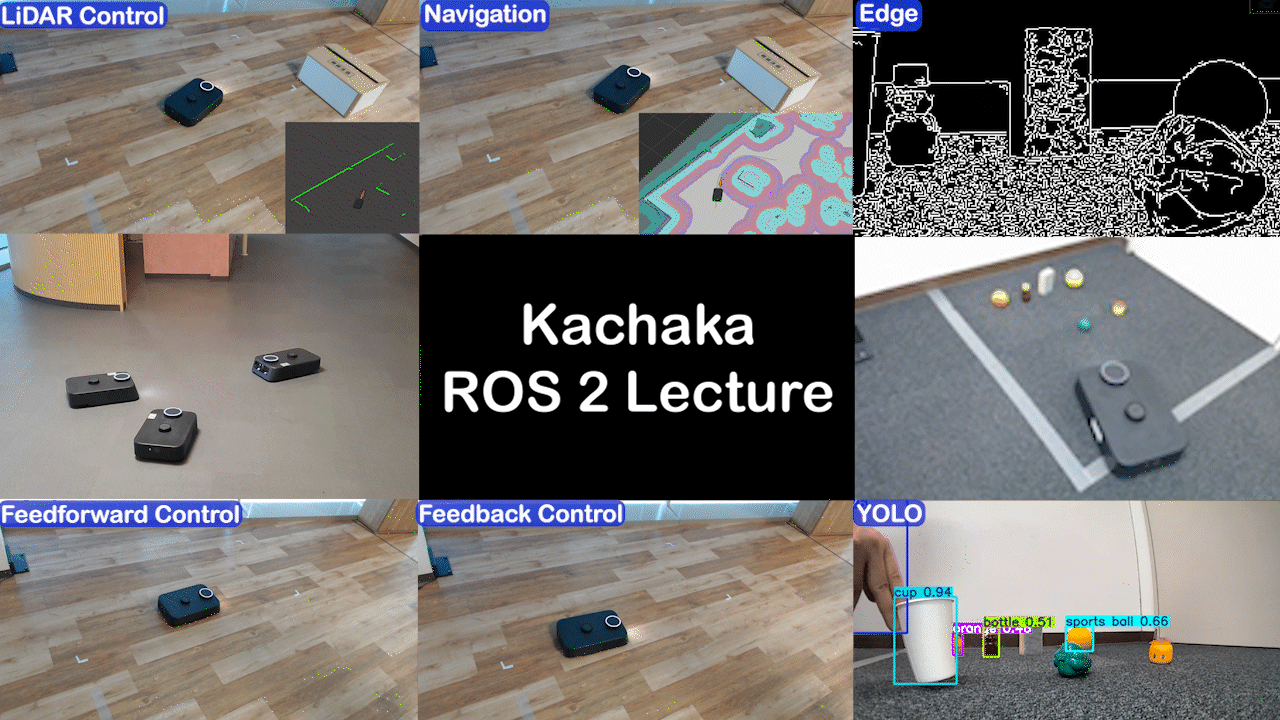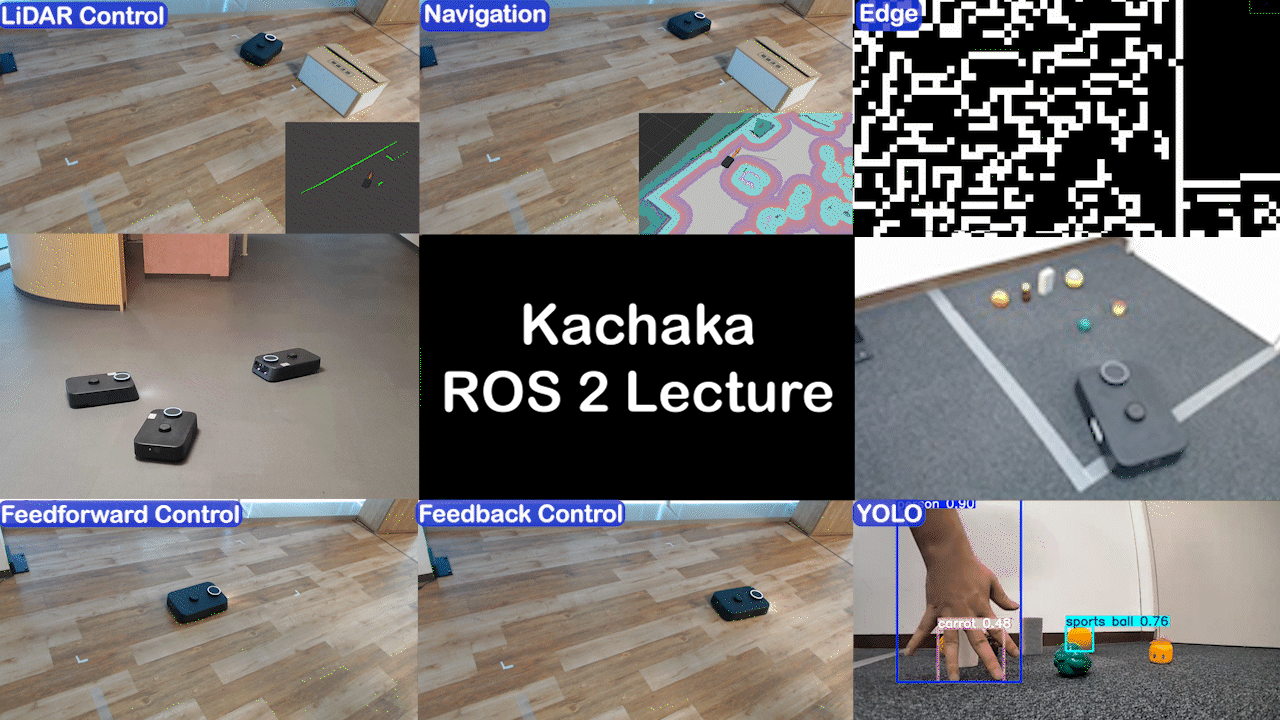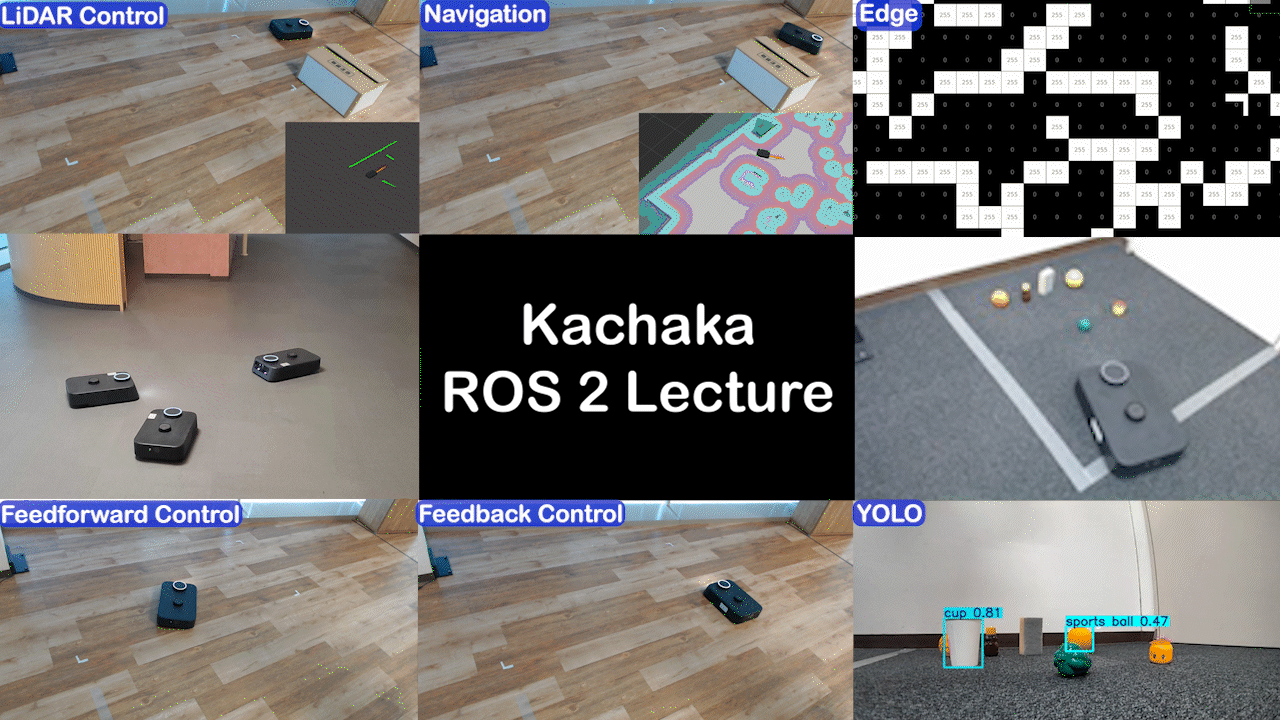
カチャカとROS 2で学ぶAIロボット入門教材
カチャカとROS 2を使ってAIロボットの基礎を学べる、無料のオープン教材.日本語・英語に対応し、大学講義でも使用.
Project
Foundation Model and Robotics
基盤モデル×ロボティクスをテーマにした公開講義スライド.中学生から大学院生を対象に実施したオンライン講義の教材を公開.
Intelligent Robot System 2023
/
arXiv Paper
· Project
TRAIL: Team Description Paper for RoboCup@Home 2023
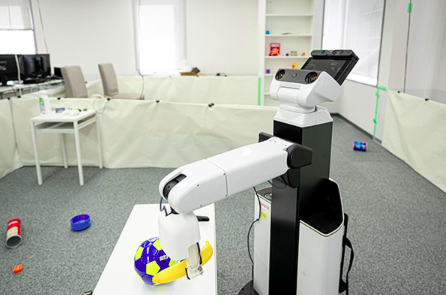
RoboCup@Home 2023のTRAILチーム論文.家庭環境でのロボット操作とナビゲーションに関する研究.
2023
/
arXiv Paper
· Project
OUXT Polaris: Autonomous Navigation System for the 2022 Maritime RobotX Challenge
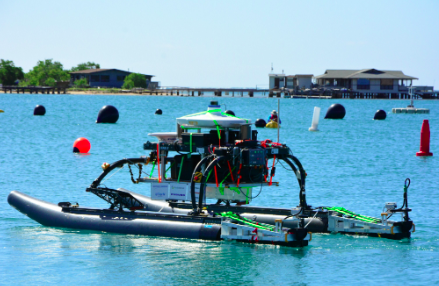
Maritime RobotX Challengeのための自律ナビゲーションシステム.海上ロボットの自律航行技術を実証.